AutoTwin-AI
🏭 AutoTwin-AI: Industrial Digital Twin, Video Telemetry & Structural Inspection Platform




An end-to-end Industrial Digital Twin, Video Telemetry & Structural Inspection Platform for vehicle ladder-frame chassis assemblies and heavy crane fabrication (Girder 516).
- v2.0 (Current): Factory Video Telemetry POC — Automated Arc-On Time, Spatter Particle Tracking, Process Stability Indices, Manual Fabrication Telemetry, and Crane Gallery 28-Stage Takt Benchmarks.
- v1.0: Full-Stack 3D Ladder-Frame Chassis Digital Twin, 361k CAD vertex clustering, and Convolutional Autoencoder for microscopic defect detection.
- v3.0 (Roadmap): Spatiotemporal ConvLSTM 5D Tensor Model for Next-Frame Prediction (branch
feature/v3-convlstm).
🎬 v2.0: Factory Video Telemetry & Inspection POC
AutoTwin-AI v2.0 integrates real-world factory video telemetry to benchmark robotic welding against internal controller logs, monitor human manual fabrication, and enforce takt compliance across the Crane Gallery Assembly.
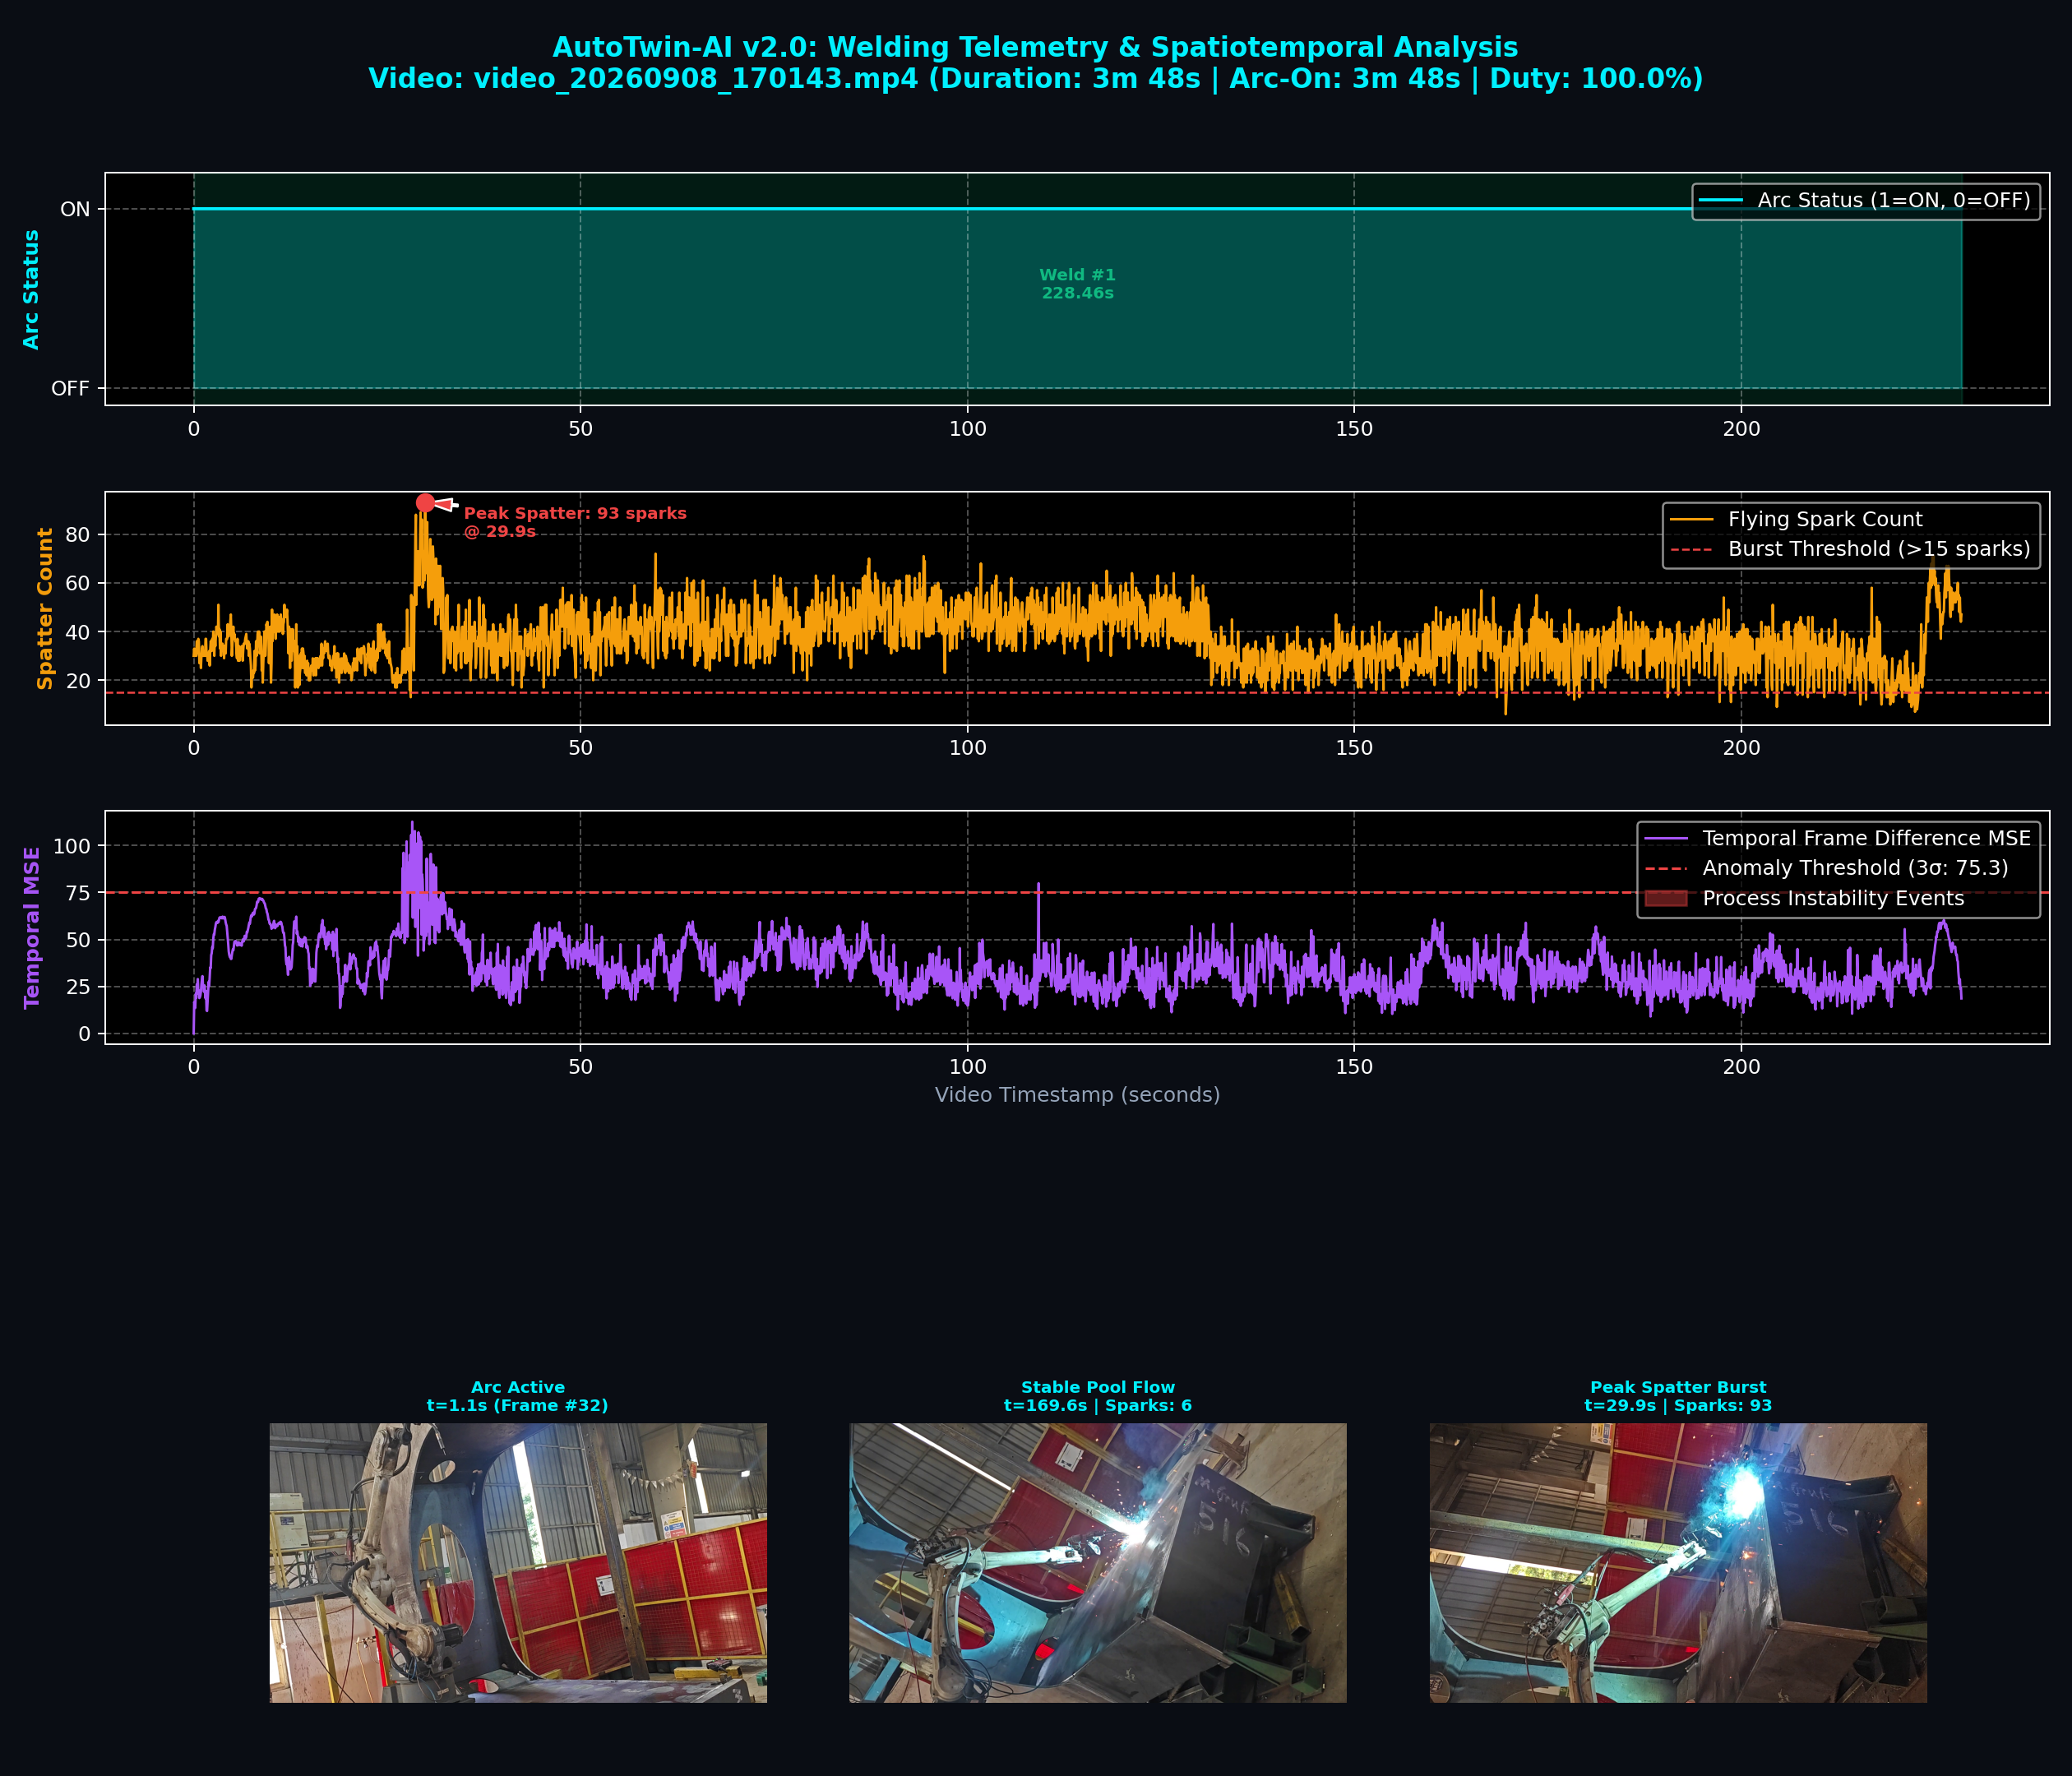
1. Robotic Welding Benchmarks (Girder 516 Seams)
The robotic welding videos serve as a controlled benchmark. Vision-derived metrics are compared against the robot’s internal controller logs to validate measurement accuracy:
| Metric | Girder 516 // Inner Corner Seam (170143) |
Girder 516 // Lower Flange Seam (171604) |
|---|---|---|
| Video Duration | 228.52s (3m 48s) | 268.03s (4m 28s) |
| Total Frames | 6,860 @ 30.02 FPS | 8,046 @ 30.02 FPS |
| Arc-On Duration | 228.46s (100.0% Duty Cycle) | 267.97s (100.0% Duty Cycle) |
| Spatter Tracking | 36.87 sparks/frame (~1,106.9 sparks/s) | 86.95 sparks/frame (~2,610.2 sparks/s) |
| Peak Spatter Burst | 93 sparks (@ $t = 29.91$s) | 297 sparks (@ $t = 257.71$s) |
| Process Stability Index | 95.04% (34 frames $> 3\sigma$) | 93.29% (54 frames $> 3\sigma$) |
| Controller Log Audit | READY FOR LOG VERIFICATION | READY FOR LOG VERIFICATION |
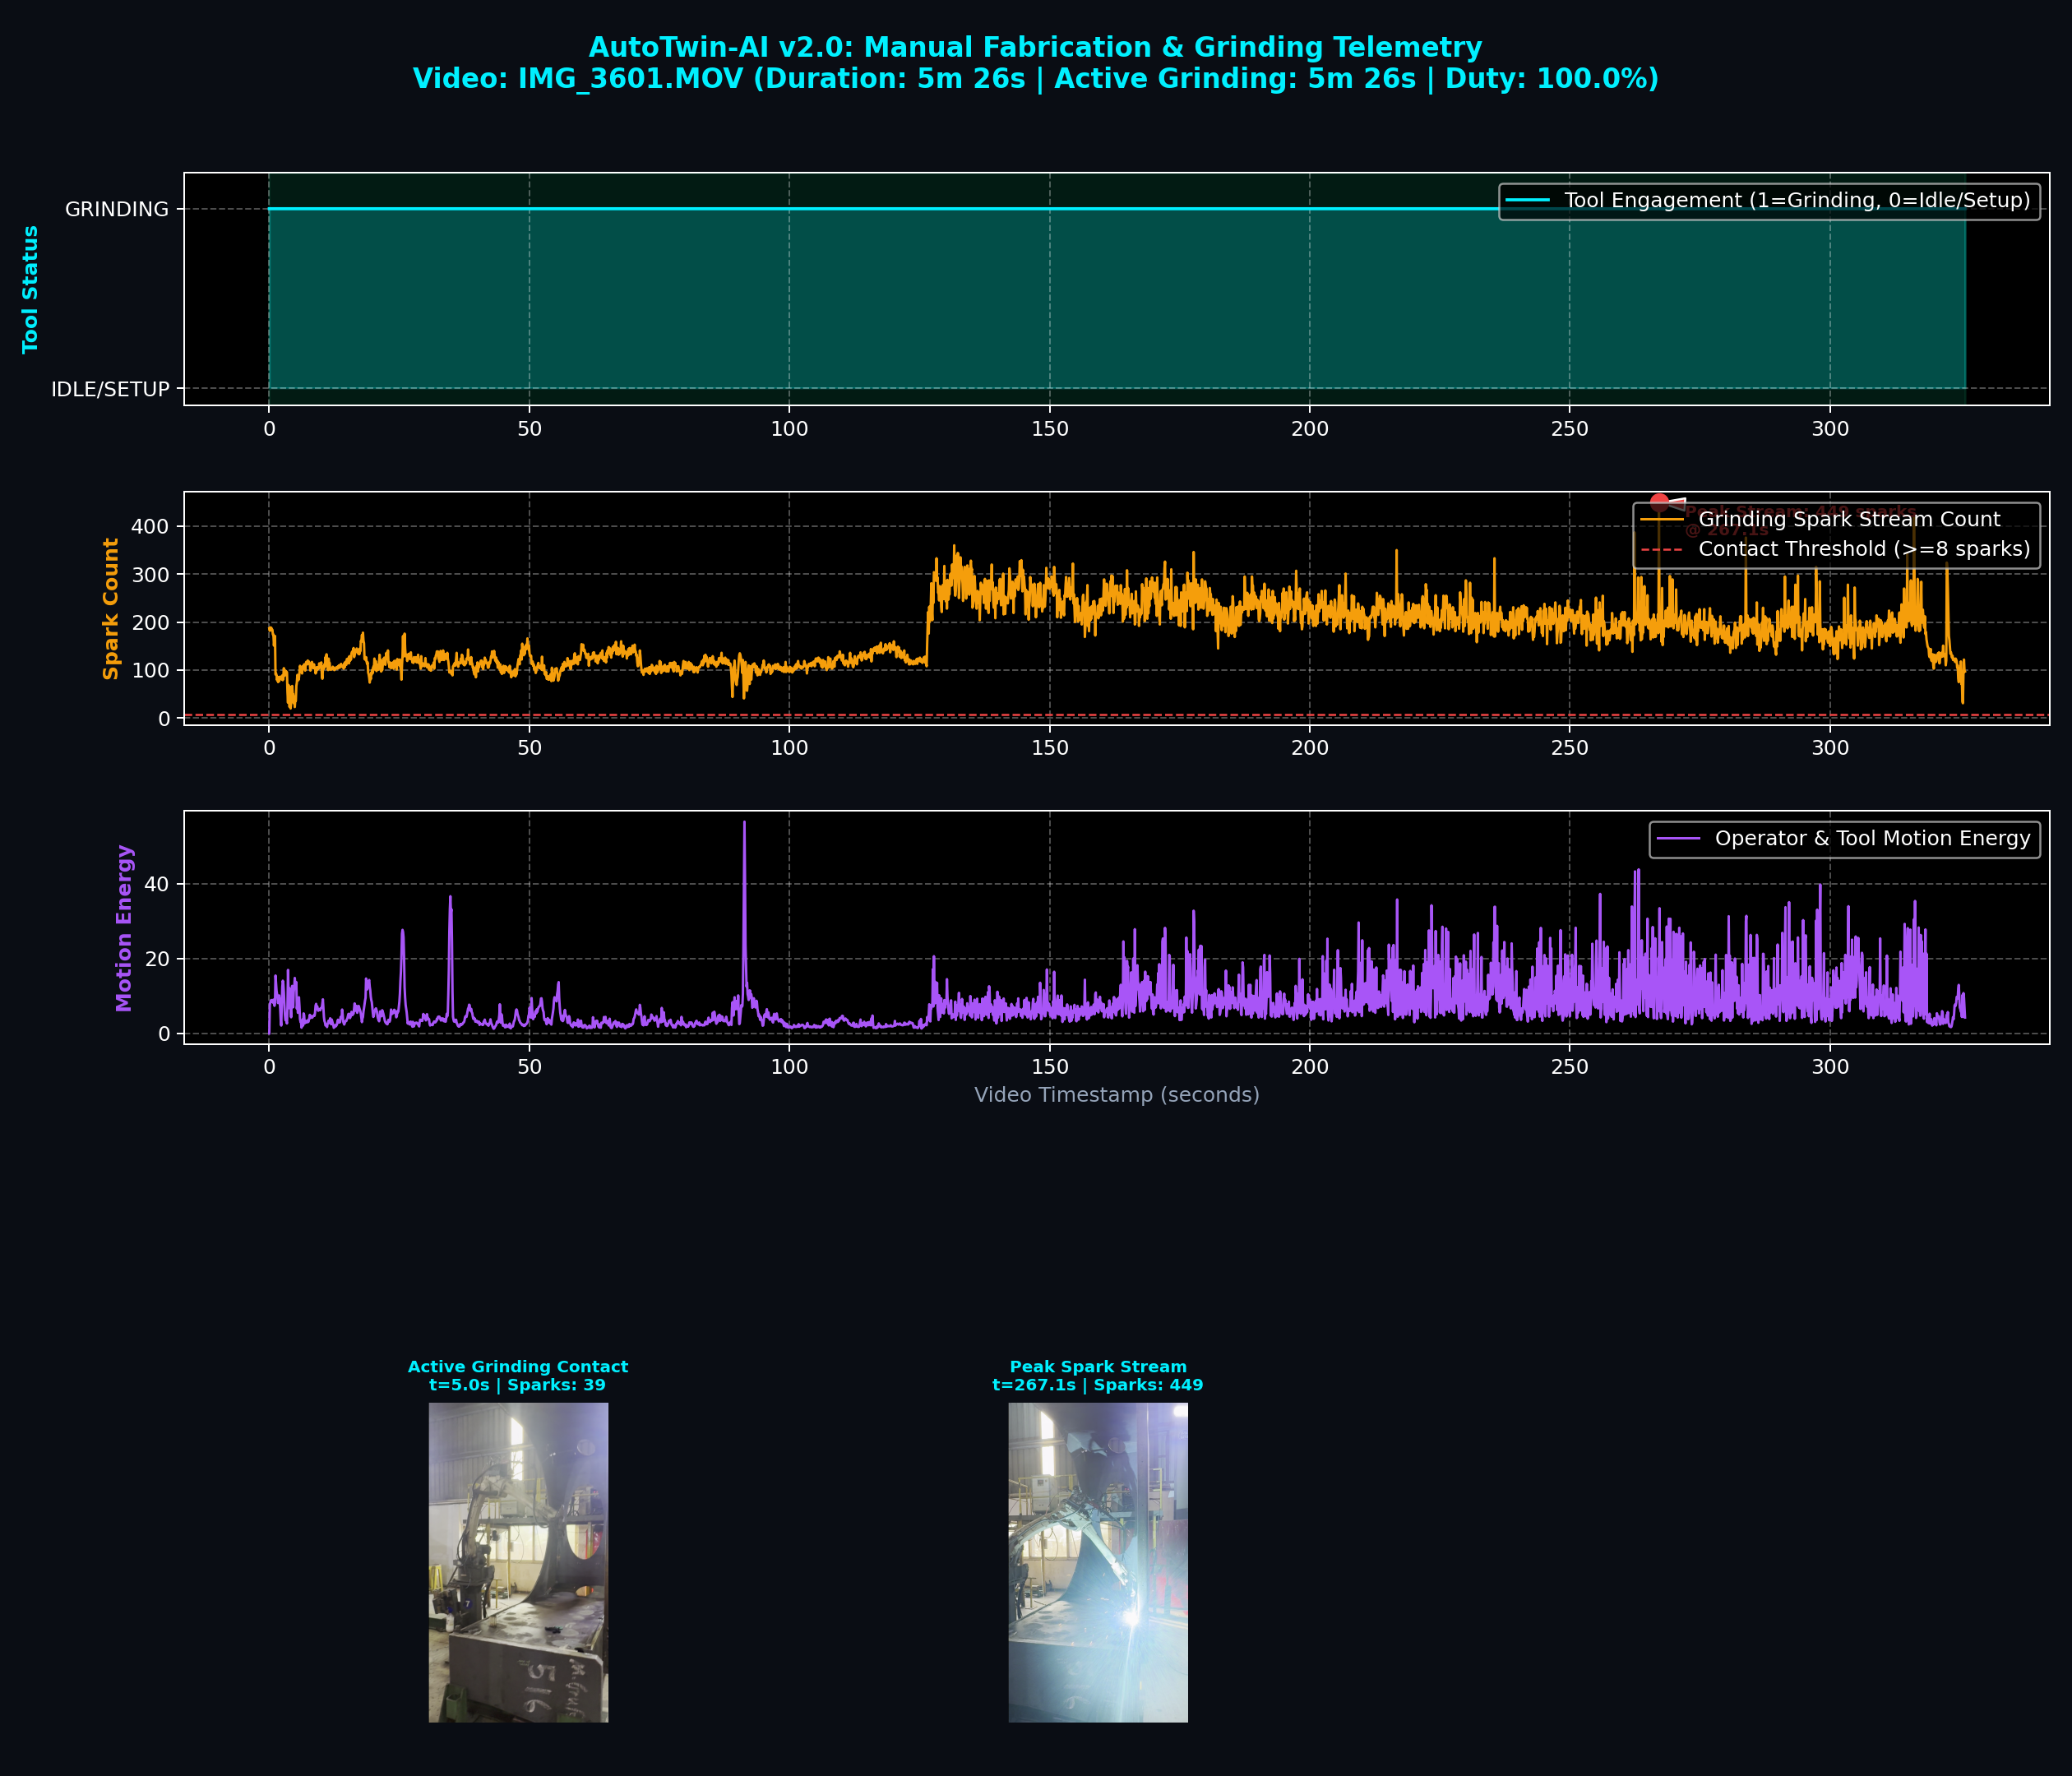
2. Manual Fabrication & Grinding Telemetry (IMG_3601.MOV)
The ultimate deployment target is human fabrication workstations. Telemetry tracks manual tool engagement and correlates against standard fabrication cycle times:
-
Duration: 326.01s (5m 26s) 9,775 frames. - Active Grinding Contact Time: 326.08s (100.0% Active Tool Engagement).
- Peak Spark Stream: 449 sparks/frame, mean motion energy 7.53.
- Crane Gallery Benchmark Correlation (
crane_gallery_stages.xlsx):- Stage #5 (I Beam UT & Cleaning): 200 min cycle vs 227 min takt (PASS).
- Stage #9 (UT inspection & Cleaning): 120 min cycle vs 227 min takt (PASS).
- Stage #19 (Assy cleaning & FW): 160 min cycle vs 227 min takt (PASS).
📸 v1.0: 3D Chassis Digital Twin & Spatial Inspection
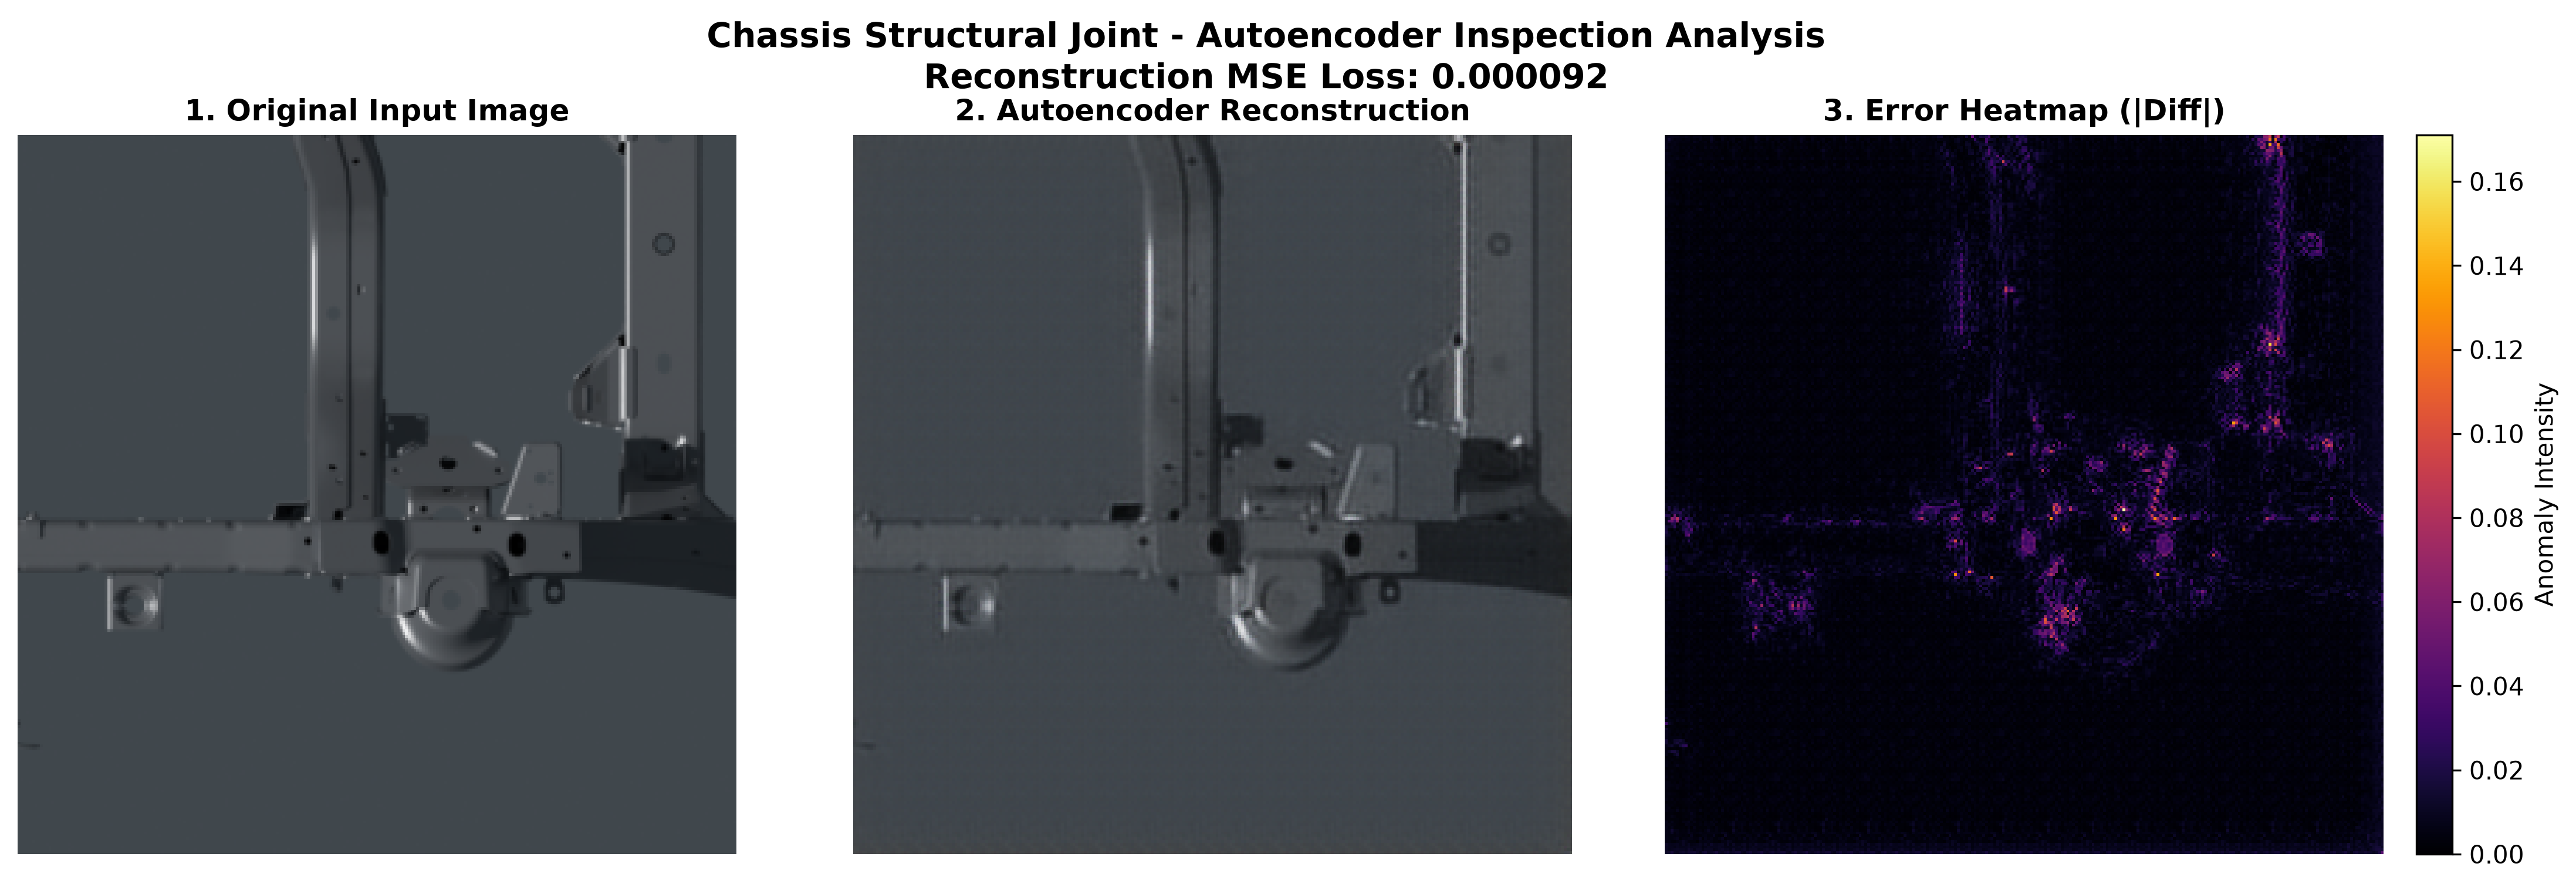
1. AI Structural Joint Anomaly Detection & Reconstruction Heatmap
The trained PyTorch Convolutional Autoencoder reconstructs baseline nominal joints and flags physical anomalies via high-intensity residual error heatmaps ($|I - \hat{I}|$):
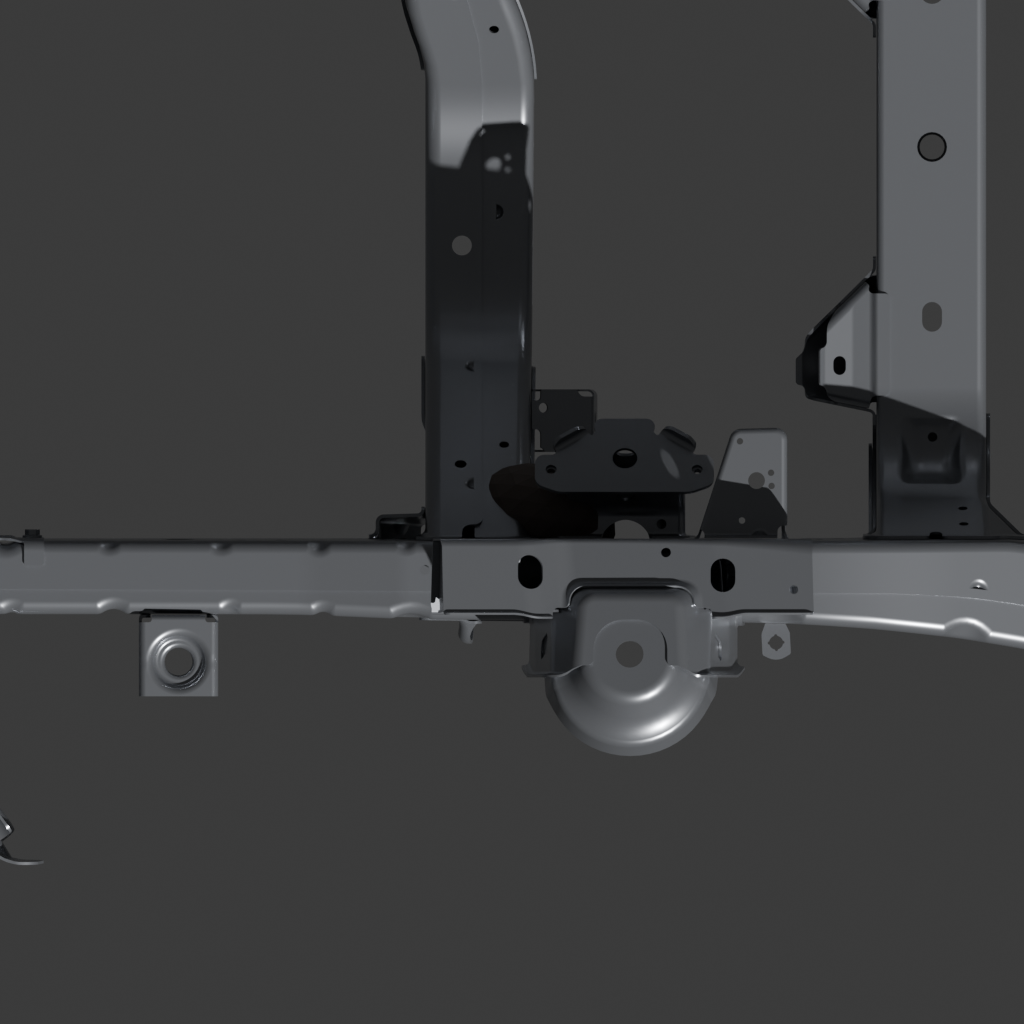
2. True Structural CAD Joint Mapping
High-density 3D spatial voxel clustering isolates structural load-bearing junctions from 361,174 CAD vertices (28000.obj):
| Top-Down Orthographic Chassis Overview | 3D Isometric CAD Perspective |
|---|---|
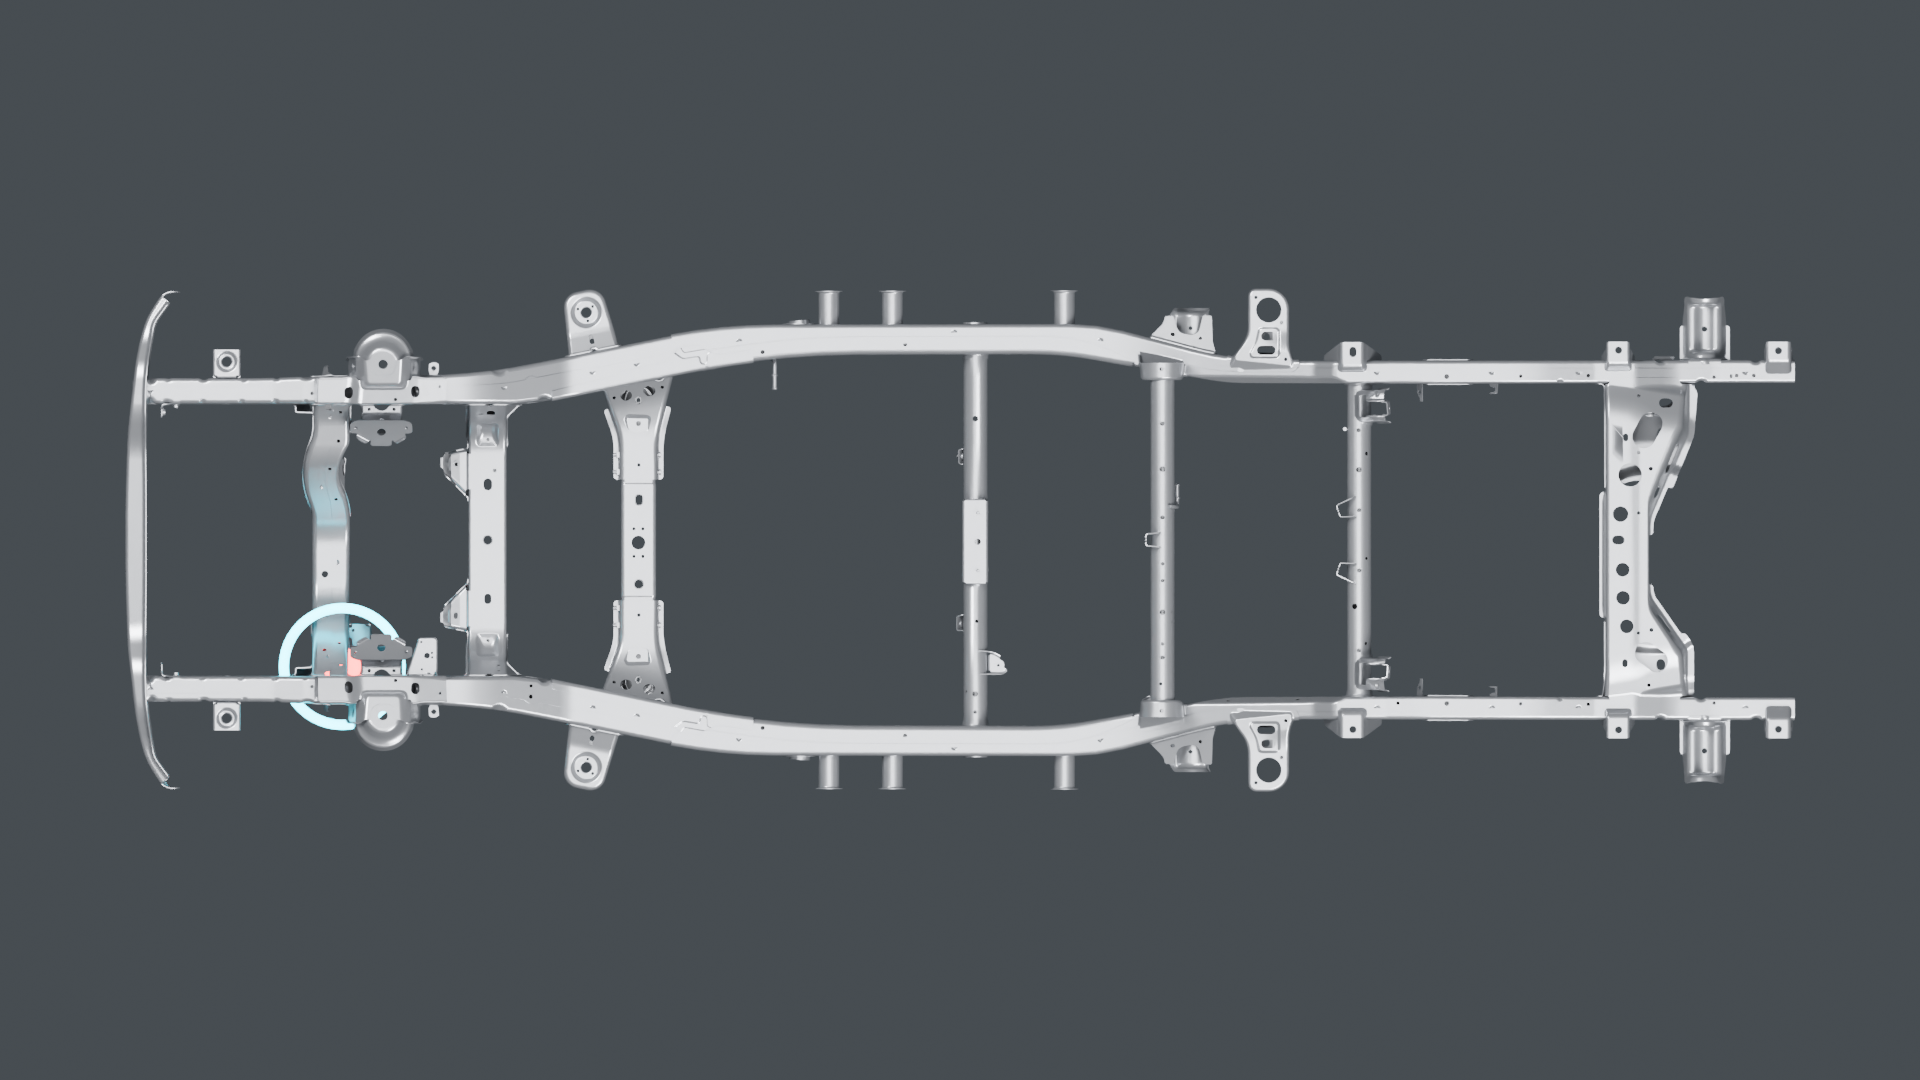 |
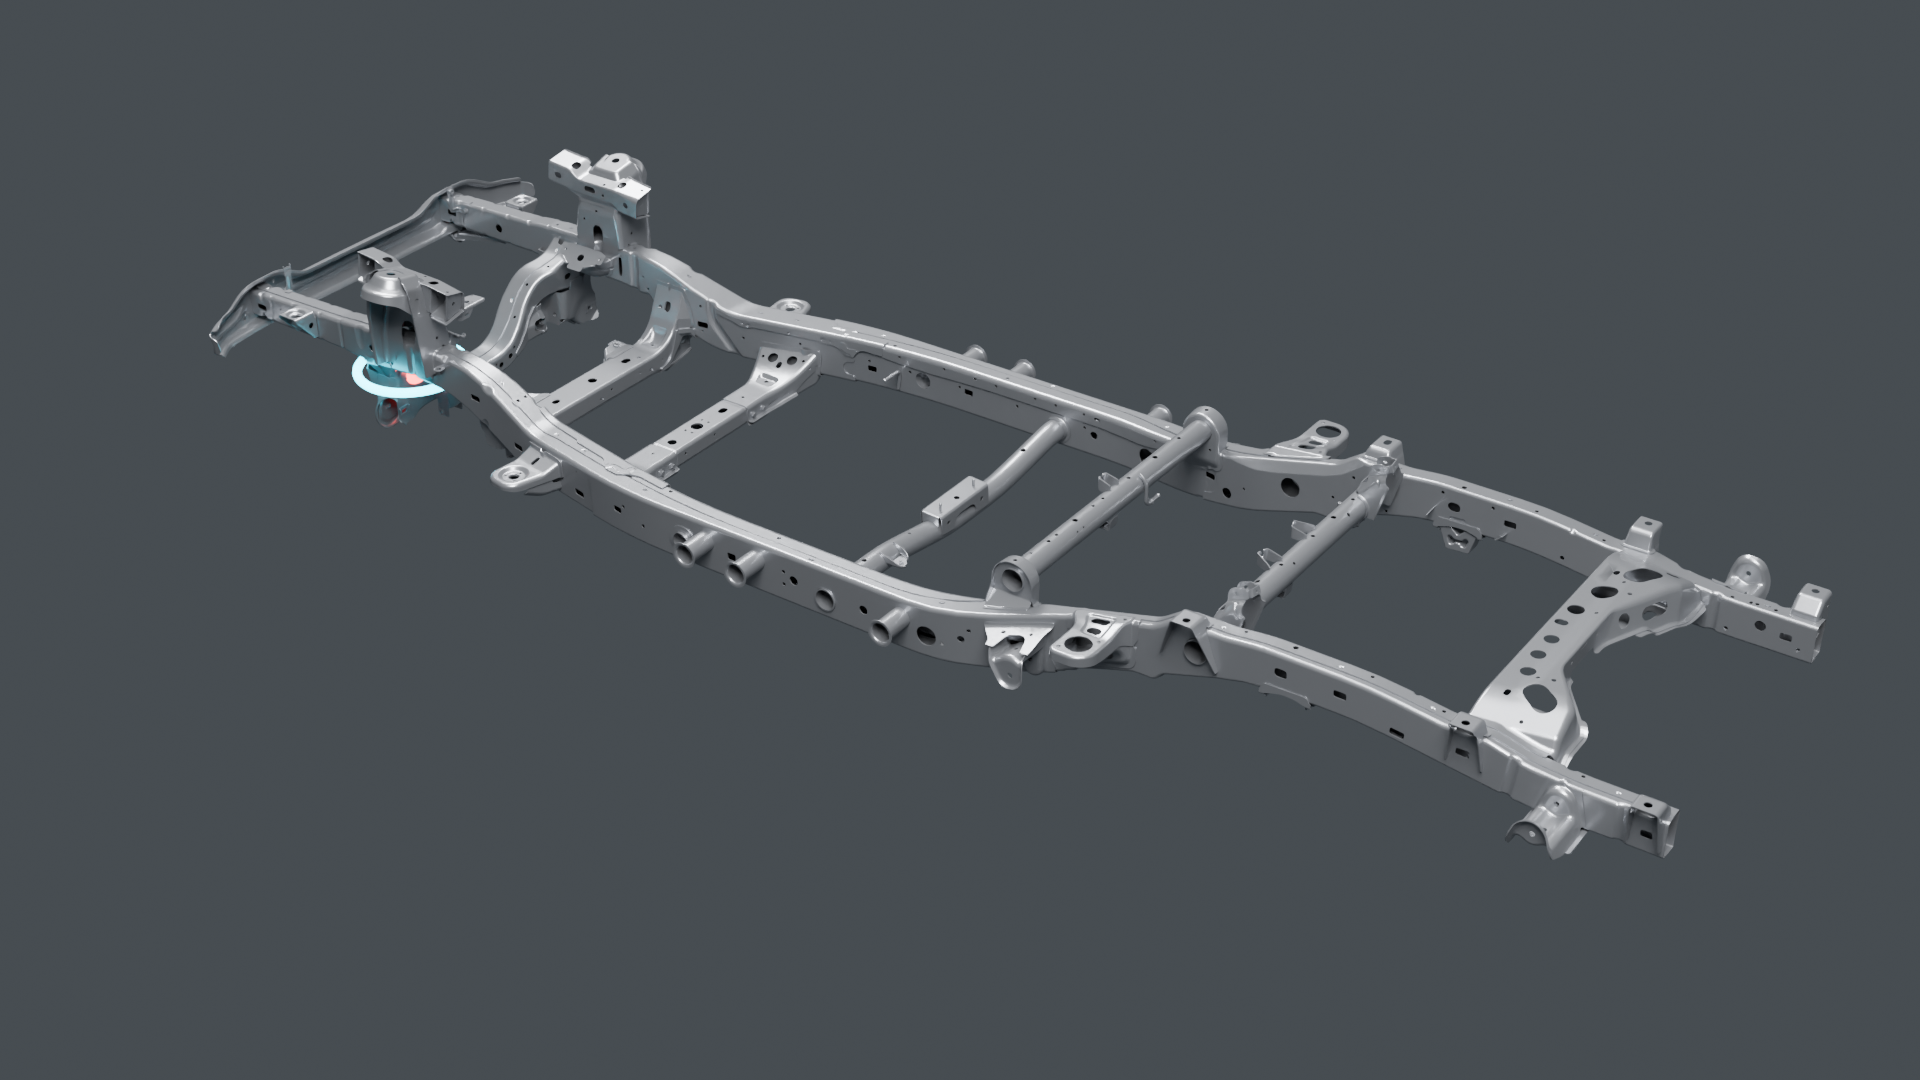 |
| Macro Top-Down Joint Crop (1:1 Sensor Framing) | High-Resolution Macro Perspective Detail |
|---|---|
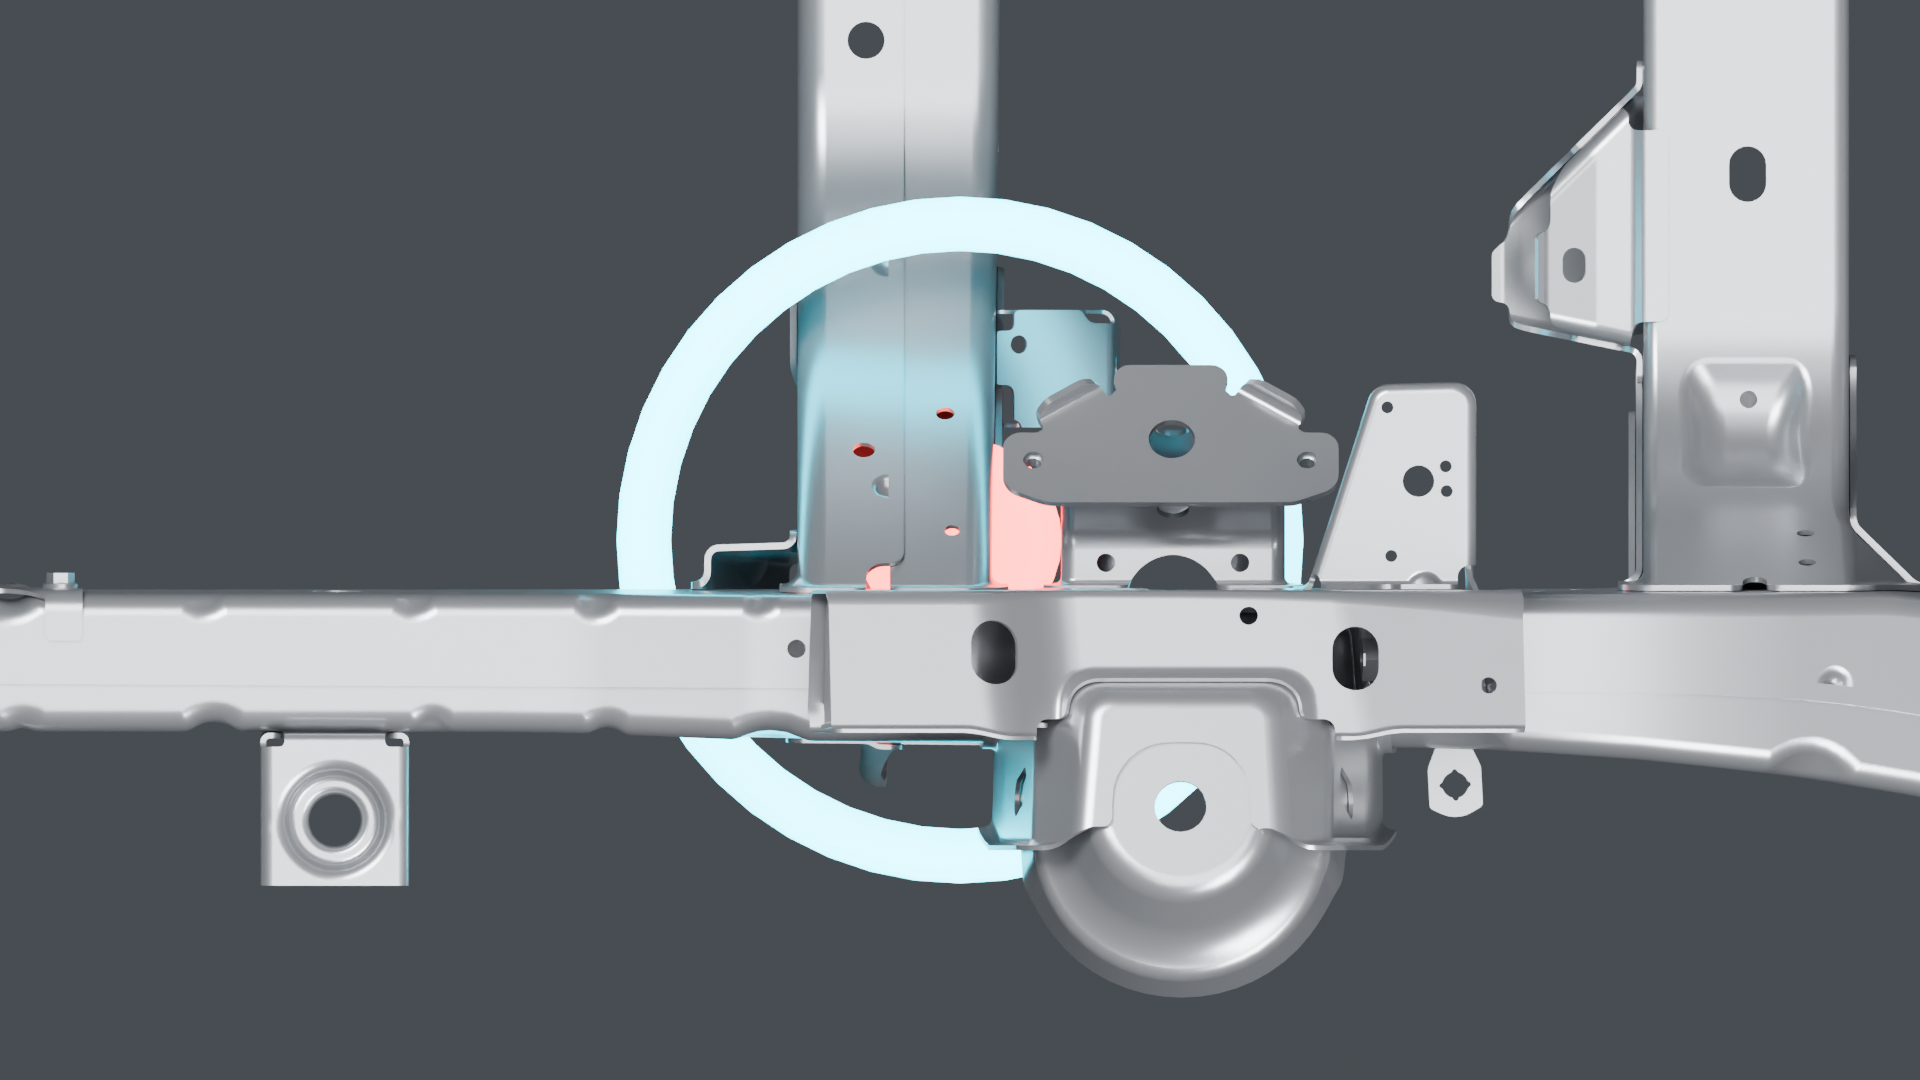 |
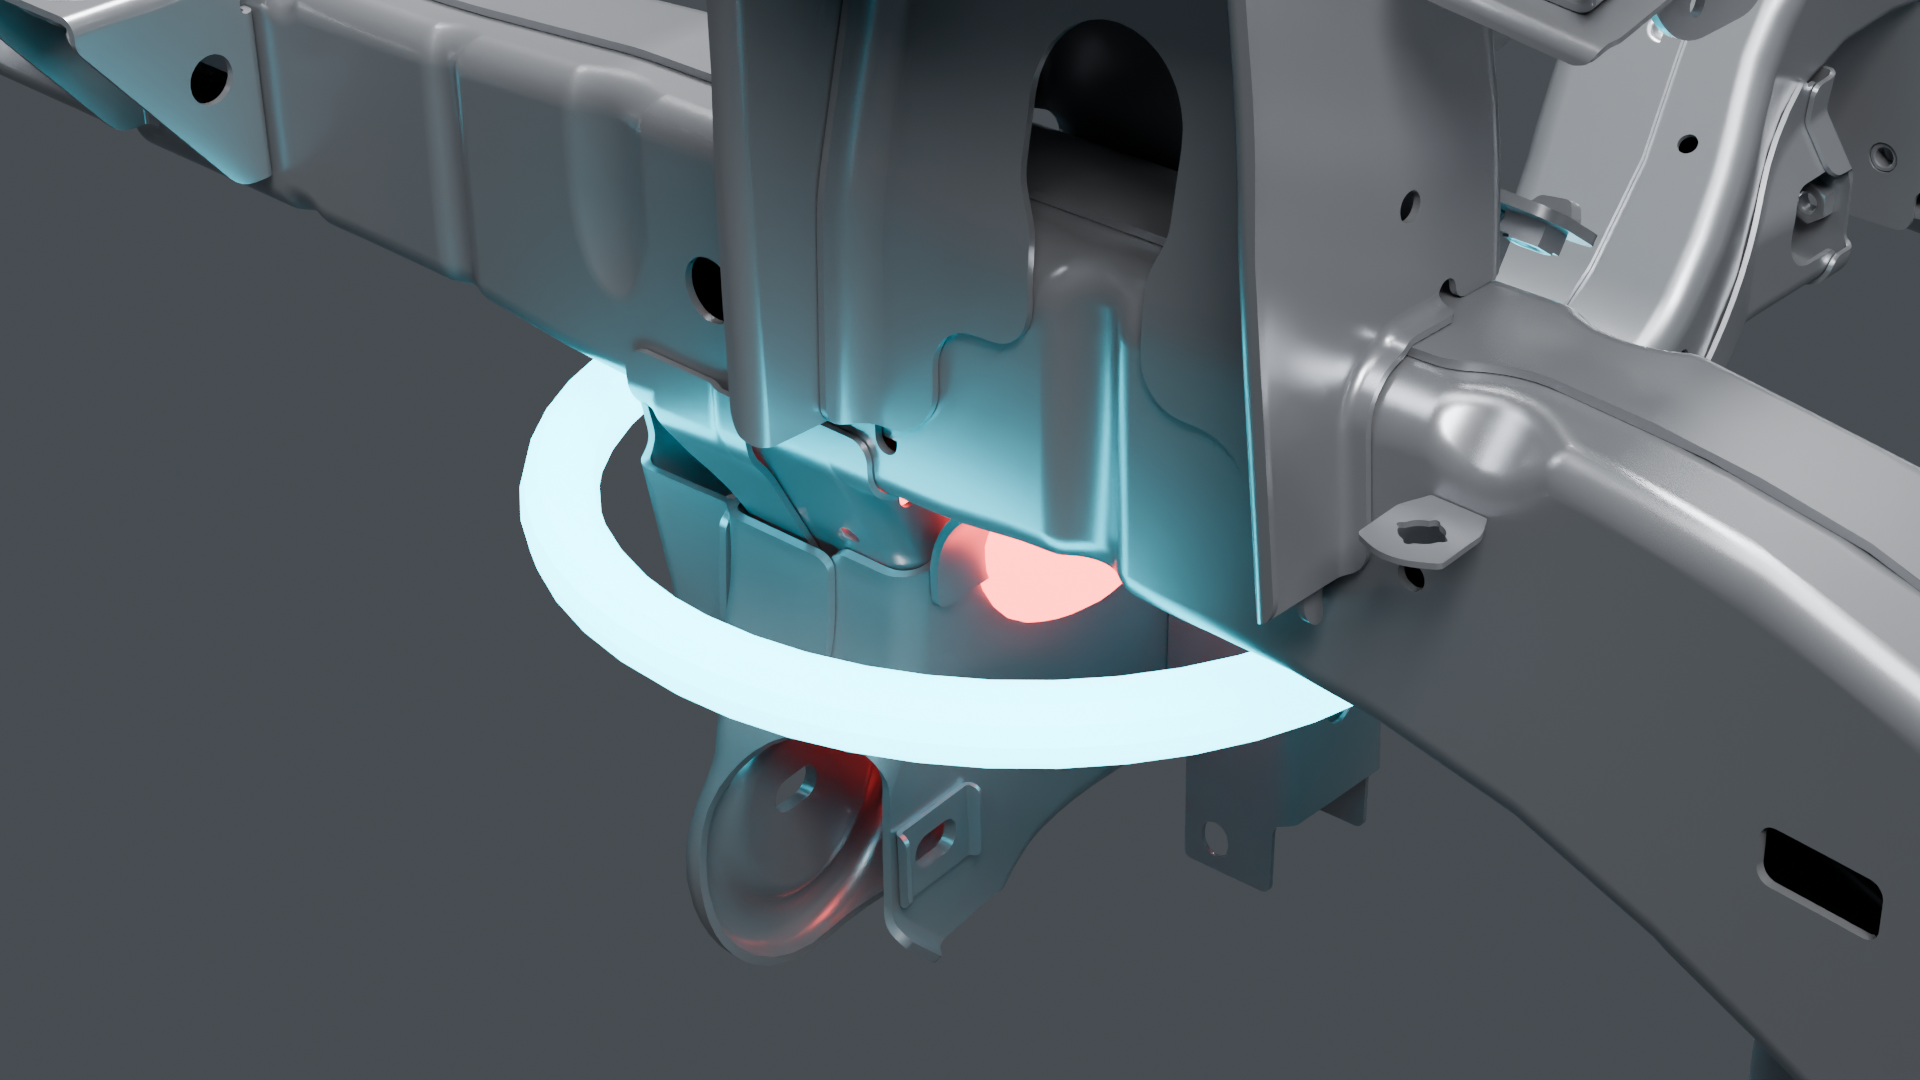 |
3. Synthetic Defect Injection (Weld Slag & Spatter)
Mathematical defect generator spawning irregular, distorted oxidic slag geometry directly onto the suspension weld seam for out-of-distribution anomaly validation:
📌 System Architecture
flowchart TD
    subgraph CADLayer ["1. CAD Ingestion & Clustering"]
        CAD["Vehicle Chassis (28000.obj - 361k Vertices)"]
        CLUSTER["3D Spatial Voxel Clustering"]
        CAD --> CLUSTER
    end

    subgraph SyntheticGen ["2. Blender OptiX Synthetic Engine (GPU)"]
        PBR["PBR Steel Shaders (Met: 0.85, Rough: 0.28)"]
        RANDOM["Domain Randomization (Light Angle, Sun Energy, Jitter)"]
        ANOMALY["Mathematical Slag / Weld Spatter Injector"]
        CLUSTER --> RANDOM
        PBR --> RANDOM
        RANDOM --> |~0.60s / frame| BASELINE["4,850+ Normal Renders (weld_normal_*.png)"]
        ANOMALY --> DEFECT_IMG["Defect Validation Frame (defective_test.png)"]
    end

    subgraph NeuralAI ["3. PyTorch Deep Autoencoder"]
        ENC["Conv2d Encoder (256x256 -> 16x16)"]
        DEC["ConvTranspose2d Decoder (16x16 -> 256x256)"]
        LOSS["MSE Reconstruction Loss (|Input - Recon|)"]
        BASELINE --> ENC --> DEC --> LOSS
    end

    subgraph BackendAPI ["4. FastAPI Gateway Service (:8000)"]
        API_JOINTS["GET /api/joints (Hotspots Database)"]
        API_INSPECT["POST /api/inspect (Live PyTorch Inference)"]
        STATIC["Static Asset Server (/static/cad, /static/assets)"]
        LOSS --> API_INSPECT
    end

    subgraph WebDashboard ["5. React + Three.js 3D Digital Twin (:5173)"]
        CANVAS["Three.js 3D Viewport (OrbitControls + CAD Gizmo)"]
        HOTSPOTS["Interactive Glowing 3D Hotspot Pins"]
        SIDEBAR["Live Telemetry, Anomaly Gauges & Residual Heatmaps"]
        RAYCAST["Click-to-Find CAD Coordinate Raycaster"]
        STATIC --> CANVAS
        API_JOINTS --> HOTSPOTS
        API_INSPECT --> SIDEBAR
    end
⚡ Key Capabilities
- 3D WebGL Digital Twin Control Room (React + Three.js):
- Full-scale 4.85-meter vehicle chassis rendered with PBR metallic reflections and shadows.
- Interactive 3D CAD Orientation Gizmo with clickable axis alignment ($X, Y, Z$) and quick-view presets (ISO, TOP, SIDE, FRONT).
- Built-in Click-to-Find CAD Raycaster that logs exact 3D surface coordinates when clicking the metal mesh.
- Cyber-industrial dark UI with live telemetry, defect gauges, and scrollable heatmap inspection reports.
- Blender Cycles OptiX GPU Acceleration:
- Accelerated via NVIDIA RTX GPU with hardware AI neural denoising.
- Generates photorealistic
1024x1024frames in ~0.60s – 0.80s (~80x speedup over CPU). - In-memory persistent datablocks avoiding operator garbage collection bottlenecks.
- Physics-Informed Domain Randomization:
- Multi-axis sun angle variance (Azimuth $0^\circ-360^\circ$, Pitch $25^\circ-70^\circ$, Roll $\pm 20^\circ$).
- Dynamic factory lighting intensity shifts (
3.0to8.5energy). - Sub-millimeter sensor mounting vibration and focal jitter ($\pm 0.03$ X/Y, $\pm 0.05$ Z, $\pm 3.5^\circ$ roll).
- Deep Convolutional Autoencoder (CAE):
- 4-stage convolutional downsampling with batch normalization and LeakyReLU activations.
-
Generates pixel-accurate reconstruction difference heatmaps ($ \text{Input} - \text{Reconstruction} $) to pinpoint localized structural defects.
📊 Structural Joint Mapping Table
| Preset Key | Structural Joint Name | 3D CAD Coordinates $(X, Y, Z)$ | Local Vertices | Structural Details |
|---|---|---|---|---|
rear_sus_bracket (Defect Target) |
Rear Suspension Spring Perch | [1.358, 0.220, 0.500] |
18,395 | Rear spring perch tower and damper hardpoints (Slag defect test target). |
front_sus_bracket_left |
Front-Left Suspension Joint | [-1.227, 0.140, 0.398] |
29,947 | A-arm suspension mount, cross-tube weld interface, and frame rail flange. |
front_sus_bracket_right |
Front-Right Suspension Joint | [-1.185, 0.140, -0.416] |
26,822 | Symmetrical right A-arm bracket and gusset stiffener. |
engine_mount_crossmember |
Engine Mount Crossmember | [-0.644, 0.100, -0.452] |
21,557 | Heavy-duty chassis mounting bracket with reinforcement gussets. |
📂 Project Directory Structure
AutoTwin-AI/
├── .gitignore                                # Ignores large raw renders & CAD binaries
├── README.md                                 # Complete project documentation & visual gallery
├── requirements.txt                          # Python dependencies (PyTorch, FastAPI, Uvicorn, Trimesh)
│
├── backend/                                  # FastAPI Backend Service
│   └── main.py                               # API Gateway, CAD asset server & live PyTorch inference
│
├── frontend/                                 # React + Three.js 3D Web Application
│   ├── package.json                          # Node dependencies (@react-three/fiber, three, tailwindcss)
│   ├── vite.config.js                        # Vite dev server configuration
│   ├── tailwind.config.js                    # Cyber-industrial theme & palette
│   ├── postcss.config.js
│   ├── index.html                            # HTML entrypoint
│   └── src/
│       ├── App.jsx                           # Main dashboard, telemetry sidebar & heatmap modal
│       ├── DigitalTwinViewer.jsx             # Three.js 3D Canvas, CAD Gizmo & Hotspot Raycaster
│       ├── index.css                         # Custom cyberpunk glow styles & scanline animations
│       └── main.jsx                          # React DOM entrypoint
│
├── src/                                      # Core pipeline modules & algorithms
│   ├── __init__.py
│   ├── data_gen.py                           # Multi-joint synthetic dataset generator
│   ├── generate_autoencoder_dataset.py       # 5,000-sample domain-randomized baseline generator
│   ├── data_gen_anomalous.py                 # Synthetic structural defect & weld slag injector
│   ├── train_autoencoder_pytorch.py          # PyTorch Autoencoder training & heatmap visualizer
│   ├── data.py                               # Dataset verification & corrupted file cleaner
│   ├── generate_synthetic_data.py            # Multi-view reference renderer
│   └── debug_blender.py                      # Blender environment diagnostics
│
├── docs/                                     # Documentation assets & showcase images
│   └── assets/
│       ├── 01_full_top_view_true_joint.png
│       ├── 02_full_isometric_true_joint.png
│       ├── 03_zoomed_true_joint_top_crop.png
│       ├── 04_zoomed_true_joint_isometric_detail.png
│       ├── defective_test.png
│       └── reconstruction_analysis.png
│
├── cad_model/                                # Raw CAD assets (361k vertex chassis)
│   └── 28000.obj
│
├── joint_inspection/                         # Structural joint inspection metadata
│   └── joint_info.json                       # 3D spatial coordinates & cluster properties
│
├── models/                                   # Trained neural network artifacts
│   ├── autoencoder_best.pth                  # Best model checkpoint (PyTorch weights - 9.38 MB)
│   └── reconstruction_analysis.png
│
└── synthetic_dataset/
    ├── autoencoder_baseline/                 # 4,855 domain-randomized normal baseline frames
    │   └── manifest.json                     # Ground-truth camera/lighting metadata
    └── defective_test.png                    # Injected anomaly validation frame
🚀 Quickstart Guide
1. Environment Setup
# Clone the repository
git clone https://github.com/Arkz-Deepak/AutoTwin-AI.git
cd AutoTwin-AI

# Install Python dependencies (PyTorch with CUDA support)
pip install -r requirements.txt

# Install Frontend dependencies
cd frontend
npm install
cd ..
2. Run the Full-Stack Digital Twin Web Application
Start the FastAPI Backend (Port 8000):
cd backend
python -m uvicorn main:app --host 0.0.0.0 --port 8000 --reload
(Interactive Swagger API docs available at http://localhost:8000/docs)
Start the React + Three.js Frontend (Port 5173):
cd frontend
npm run dev
(Open http://localhost:5173 in your browser)
3. Generate Synthetic Datasets (Blender OptiX Engine)
Generate 5,000 Baseline Images:
# Windows
$env:NUM_IMAGES="5000"
& "C:\Program Files\Blender Foundation\Blender 5.1\blender.exe" -b --python src/generate_autoencoder_dataset.py
# Ubuntu Linux
NUM_IMAGES=5000 blender -b --python src/generate_autoencoder_dataset.py
Inject a Physical Structural Defect (Weld Slag):
& "C:\Program Files\Blender Foundation\Blender 5.1\blender.exe" -b --python src/data_gen_anomalous.py
4. Train the Autoencoder & Generate Inspection Heatmaps
# Trains on GPU, evaluates reconstruction, and outputs 3-panel error heatmap
python src/train_autoencoder_pytorch.py
The script automatically generates models/reconstruction_analysis.png plotting:

- Original Frame: Input PBR industrial joint.
- Autoencoder Reconstruction: Learned clean topology.
-
Anomaly Heatmap: Absolute pixel reconstruction residual ($ I - \hat{I} $).
🛡️ License
This project is licensed under the MIT License.