Thamizhan_Skills
🚗 AI for Autonomous Systems | RISE Internship Portfolio
Internship Period: December 2025
Domain: Computer Vision, Robotics, Deep Learning, Path Planning
Status: ✅ Complete (8/8 Projects)
📖 Overview
This repository contains the complete software stack developed during the RISE Internship for AI in Autonomous Systems. The goal was to build the core modules required for a Level 3 Autonomous Vehicle, ranging from Perception (detecting lanes and humans) to Planning (A* pathfinding) and Control (PID Drone flight).
🛠️ Tech Stack
- Languages: Python 3.10, C++ (Arduino)
- Computer Vision: OpenCV, YOLOv8, MediaPipe
- Deep Learning: TensorFlow/Keras, Scikit-Learn
- Simulation: Matplotlib, Tinkercad, Turtle Graphics
- Hardware Logic: PID Control, Ultrasonic Sensors, Voice API
📂 Project Modules
👁️ Module 1: Perception (Vision & Detection)
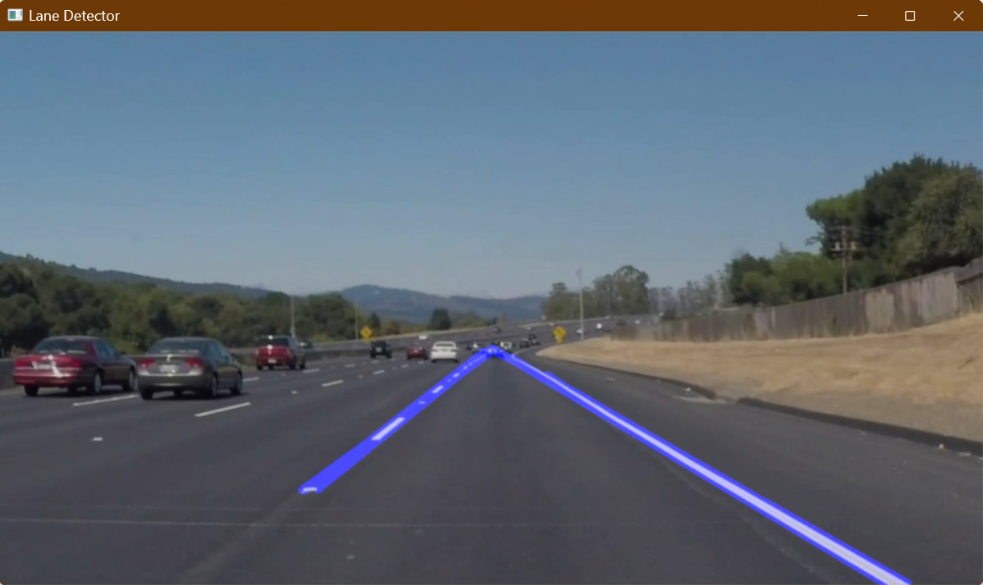
1. Real-Time Lane Detection
- Goal: Identify road boundaries in video feeds for self-driving cars.
- Tech: OpenCV, Canny Edge Detection, Hough Transform, Region of Interest (ROI) Masking.
- Result: Accurately plots lane lines on curved and straight roads.
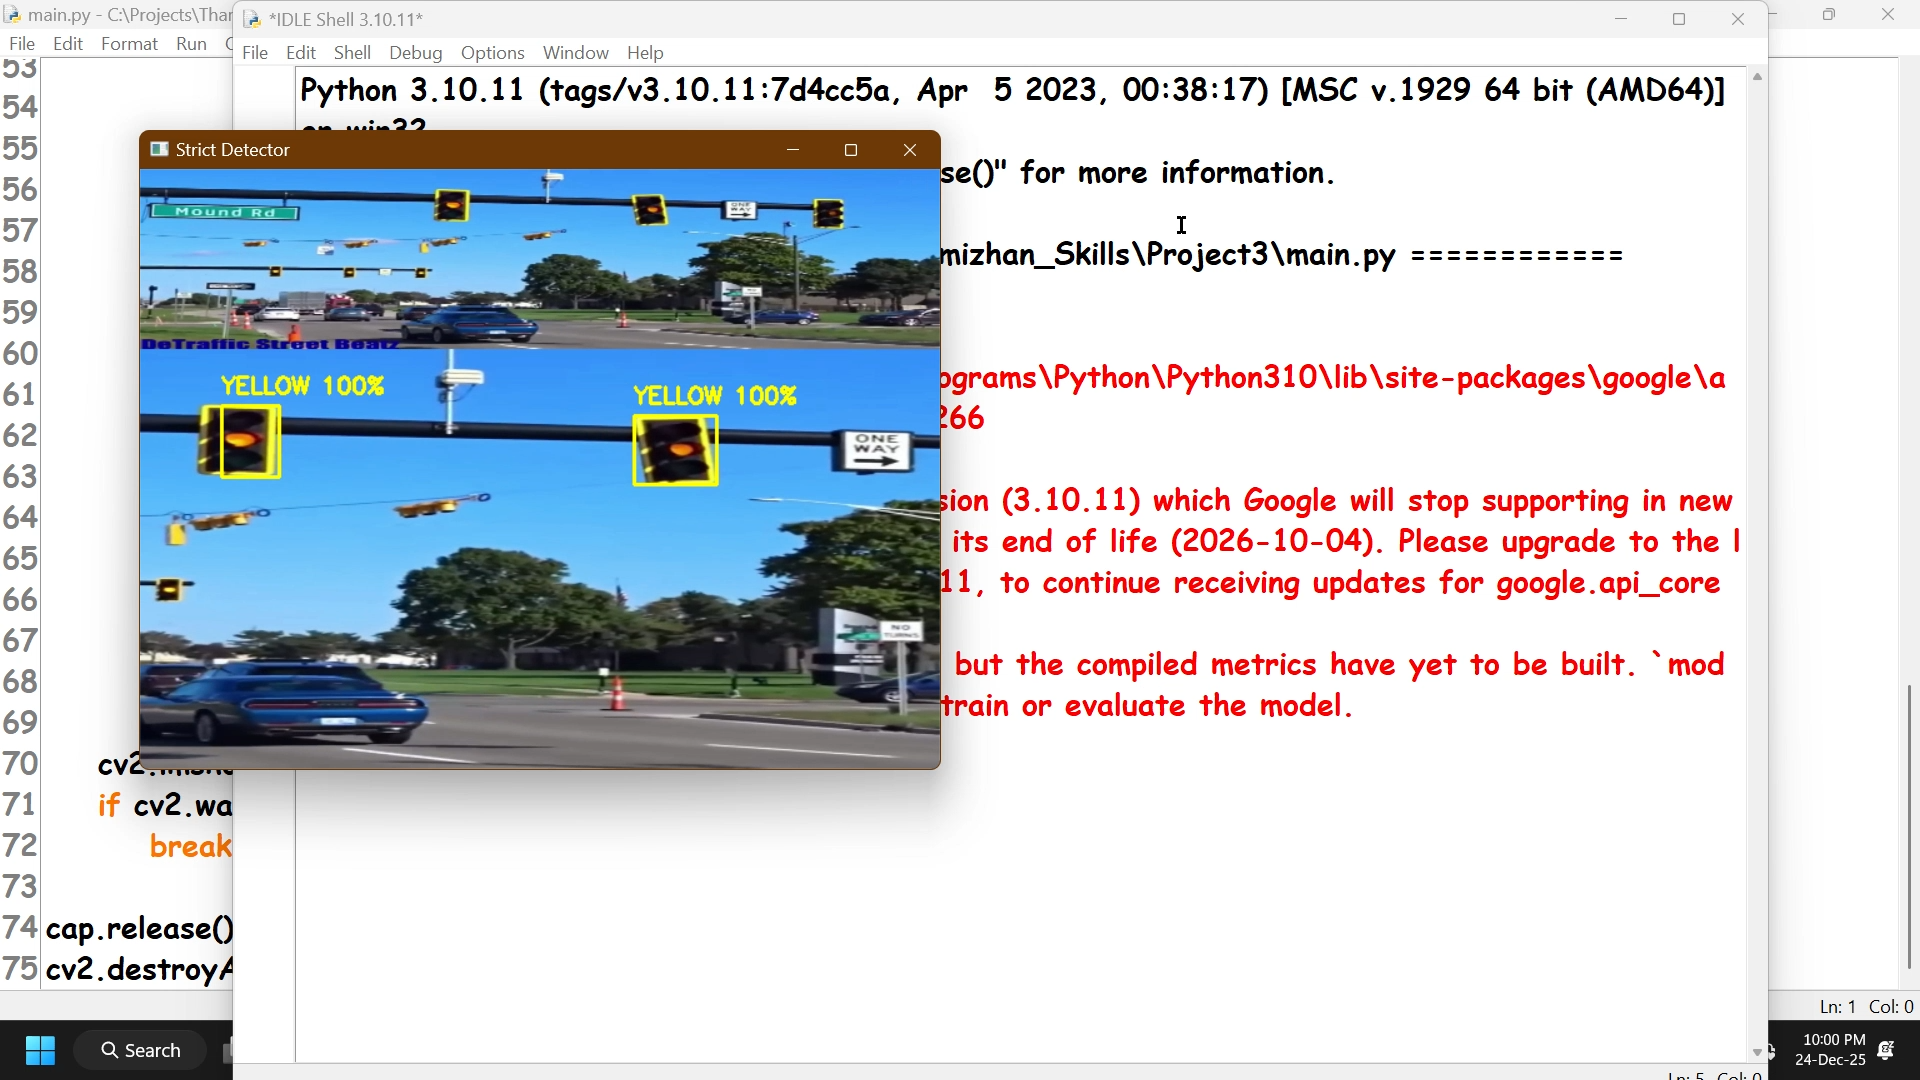
2. Traffic Light Classification (CNN)
- Goal: Detect and classify traffic signals (Red/Green/Yellow).
- Tech: Custom CNN (Convolutional Neural Network) trained on GTSRB data, HSV Color Filtering for noise removal.
- Result: 99% Validation Accuracy with real-time strict filtering for false positives.
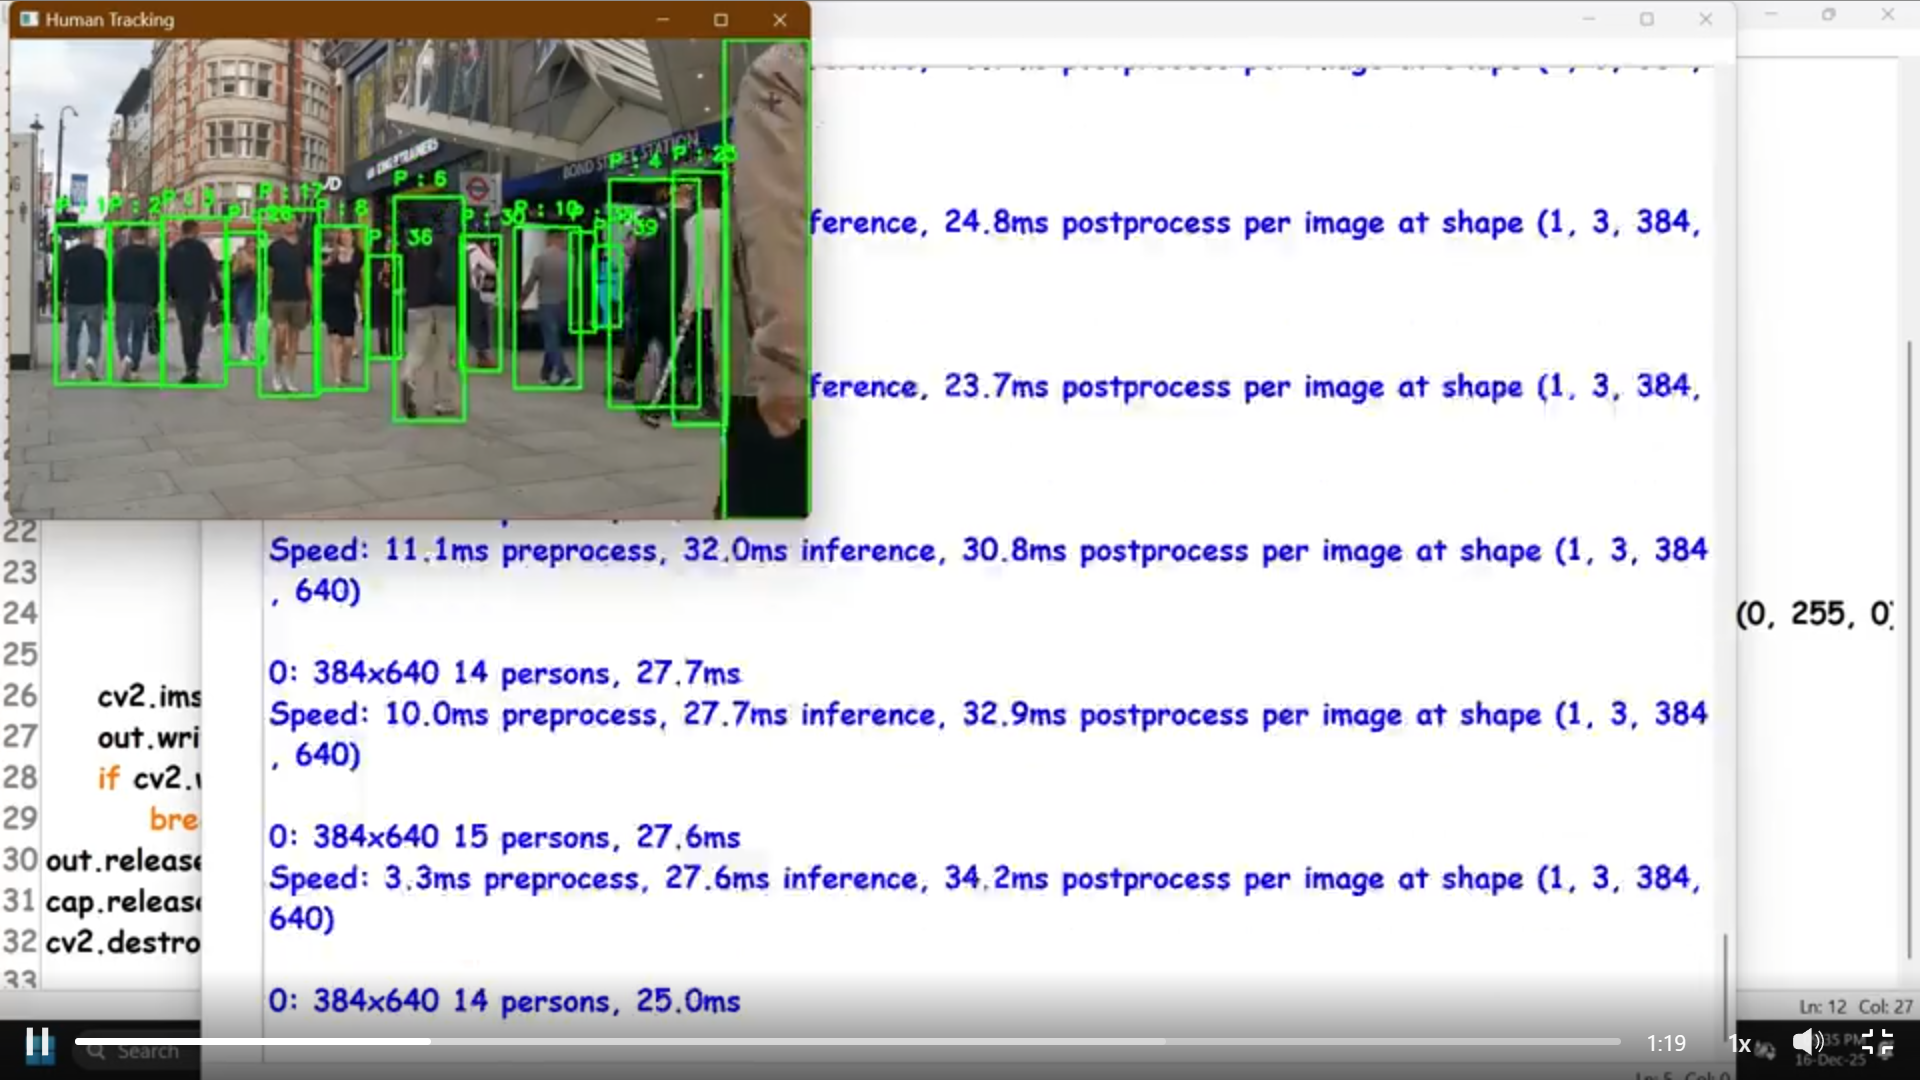
3. Human Detection & Tracking (YOLO)
- Goal: Detect pedestrians and track them to prevent collisions.
- Tech: YOLOv8 (Ultralytics), Object Tracking (ID assignment).
- Result: Real-time bounding boxes with unique IDs at 30+ FPS.
🧠 Module 2: Planning & Logic
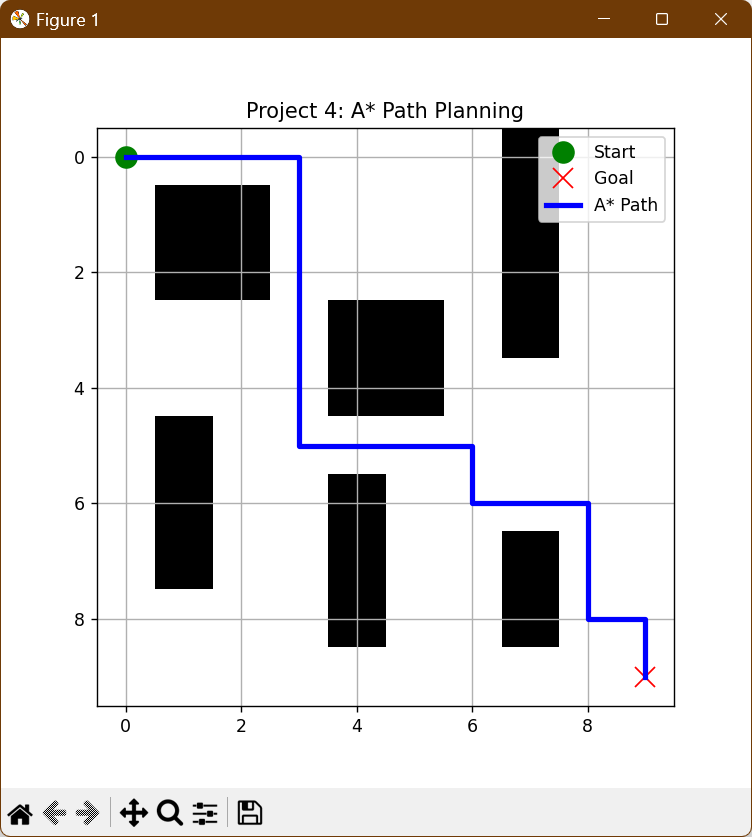
4. A* Path Planning
- Goal: Compute the optimal shortest path in a grid map with obstacles.
- Tech: A* Algorithm (Heuristic Search), Matplotlib Visualization.
- Result: Visualized optimal route finding in complex grid environments.
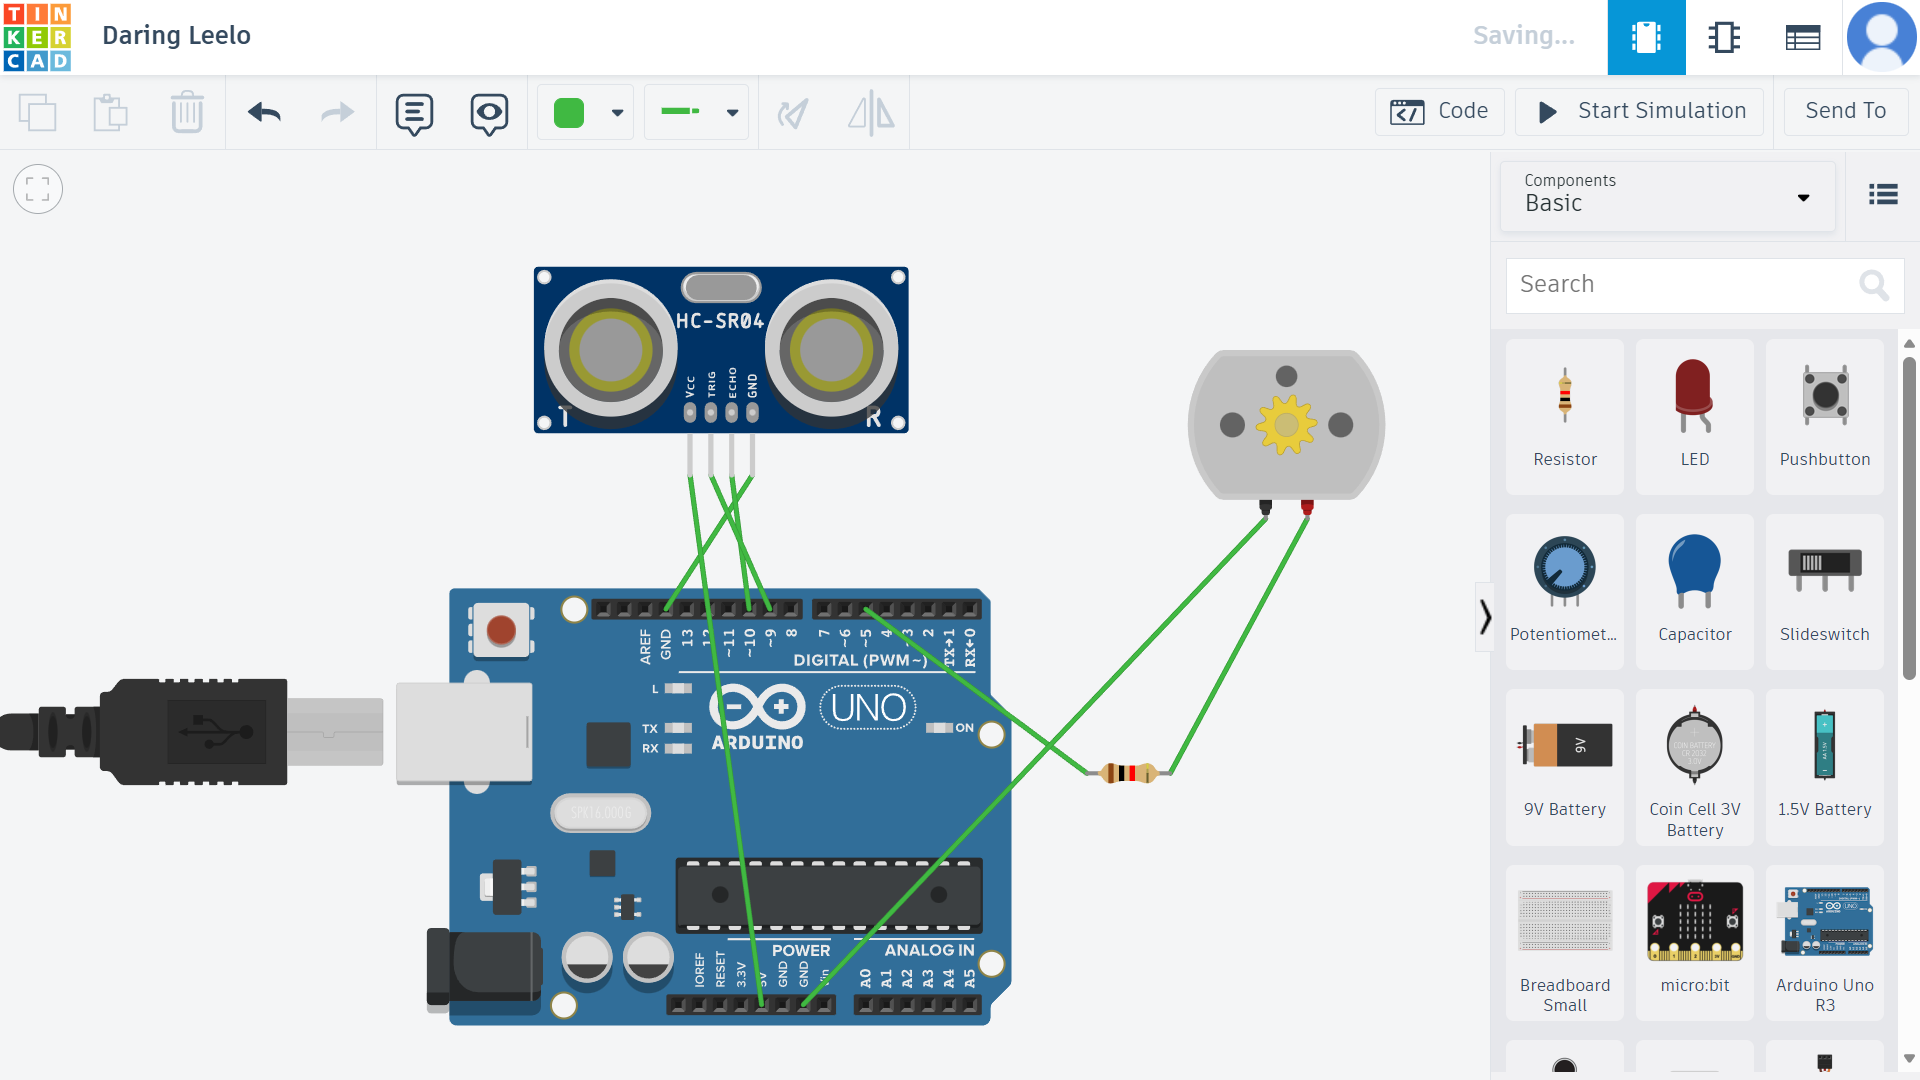
5. Obstacle Avoidance System (Simulated)
- Goal: Autonomous braking and decision-making based on sensor data.
- Tech: Random Forest Classifier (AI), Python Turtle Simulation, Tinkercad (C++).
- Result: Robot automatically slows down or triggers emergency braking when obstacles are <30cm.
🎮 Module 3: Control & Interaction
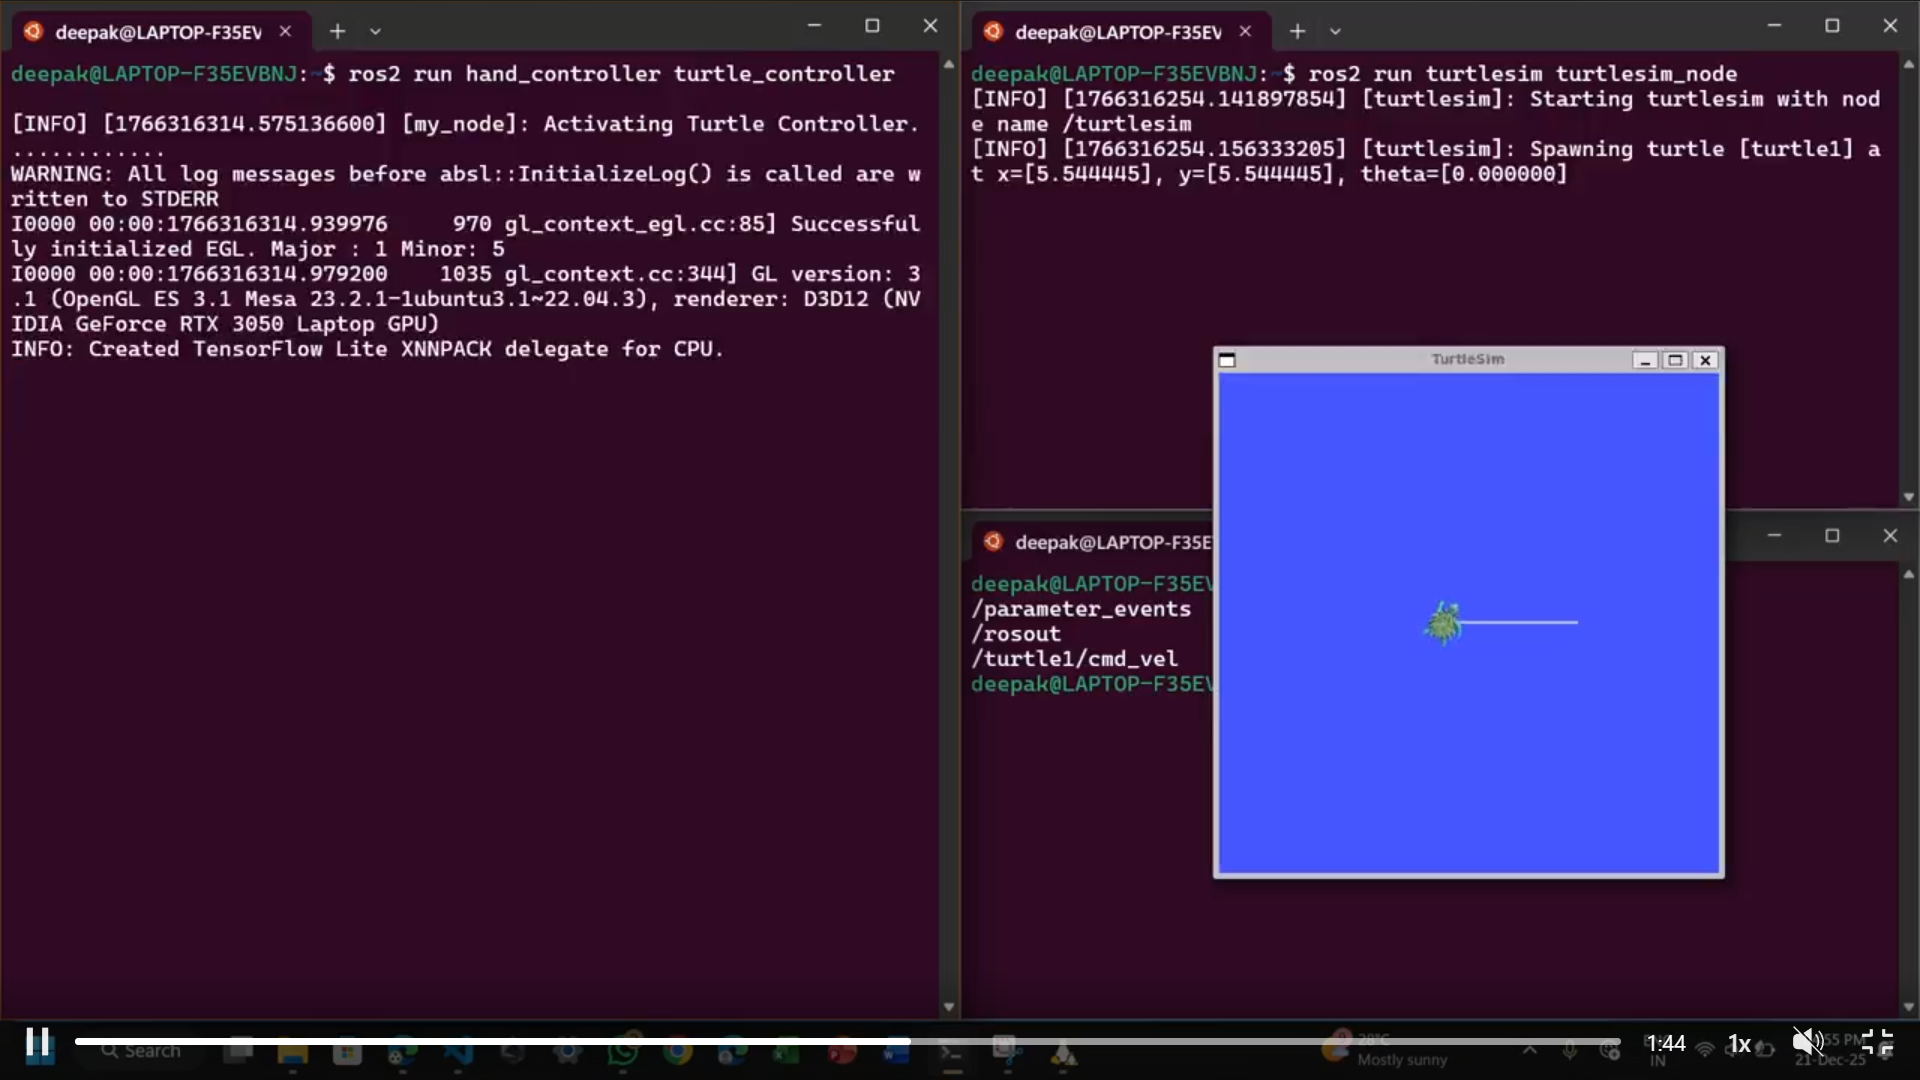
6. Gesture-Controlled Robot
- Goal: Teleoperate a robot using hand signs.
- Tech: MediaPipe Hands, Geometry Logic.
- Result: Mapped hand positions to ‘Stop’, ‘Forward’, ‘Left’, and ‘Right’ commands.
7. Autonomous Drone Flight (PID)
- Goal: Simulate stable flight dynamics for a quadcopter.
- Tech: PID Controller (Proportional-Integral-Derivative), 3D Physics Simulation.
- Result: Smooth 3D flight path through 4 waypoints including takeoff and landing.
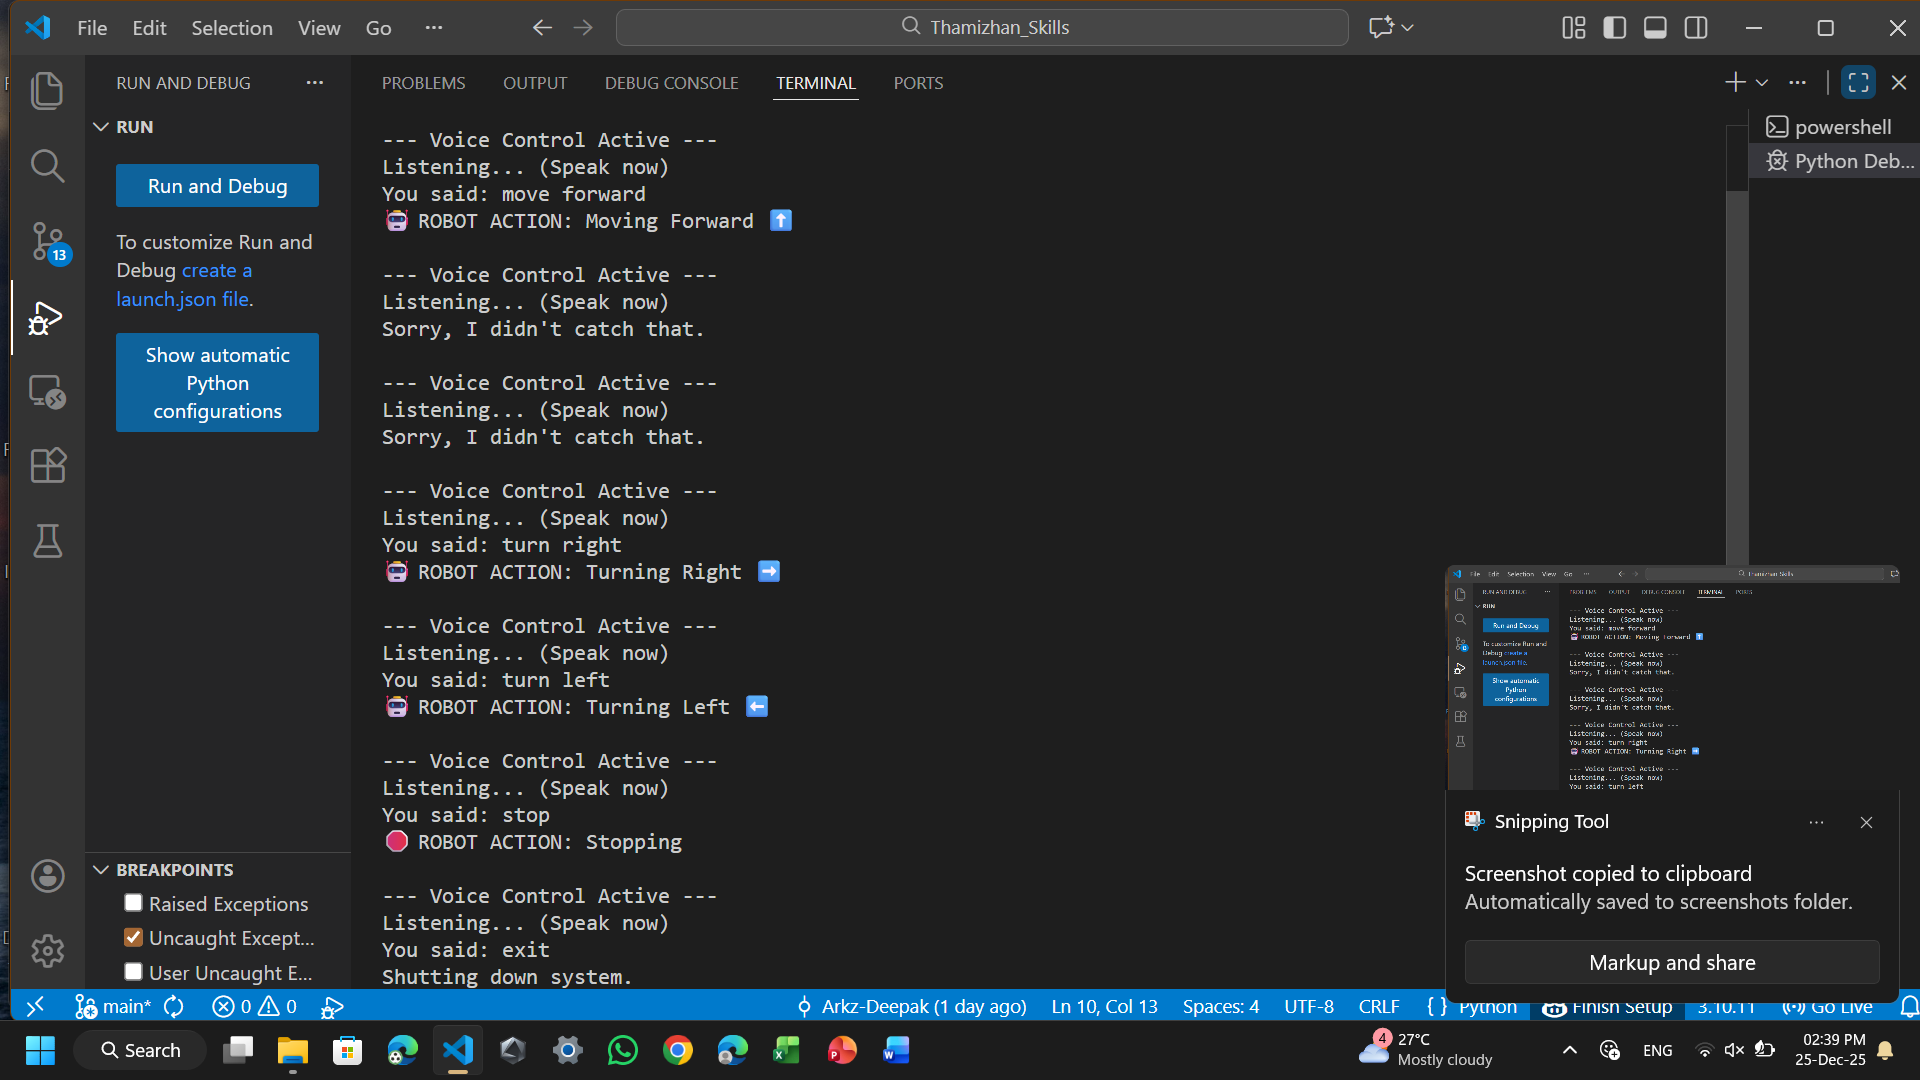
8. Voice-Activated Navigation
- Goal: Natural Language Interface for robotic control.
- Tech: SpeechRecognition Library, Google Speech API.
- Result: Converts spoken commands (“Go Forward”) into executable robot actions.
🚀 How to Run
- Clone the repository:
git clone [https://github.com/Arkz-Deepak/Thamizhan_Skills](https://github.com/Arkz-Deepak/Thamizhan_Skills) cd Thamizhan_Skills - Install Dependencies:
pip install opencv-python tensorflow ultralytics mediapipe matplotlib SpeechRecognition - Run a Module (Example: Human Detection):
python human_tracker.py
📜 Conclusion
This internship provided hands-on experience in the full robotics pipeline. By integrating Classic Computer Vision (Lanes) with Modern Deep Learning (YOLO/CNN) and Control Theory (PID), I successfully built a modular foundation for autonomous systems.
Created by Deepak R